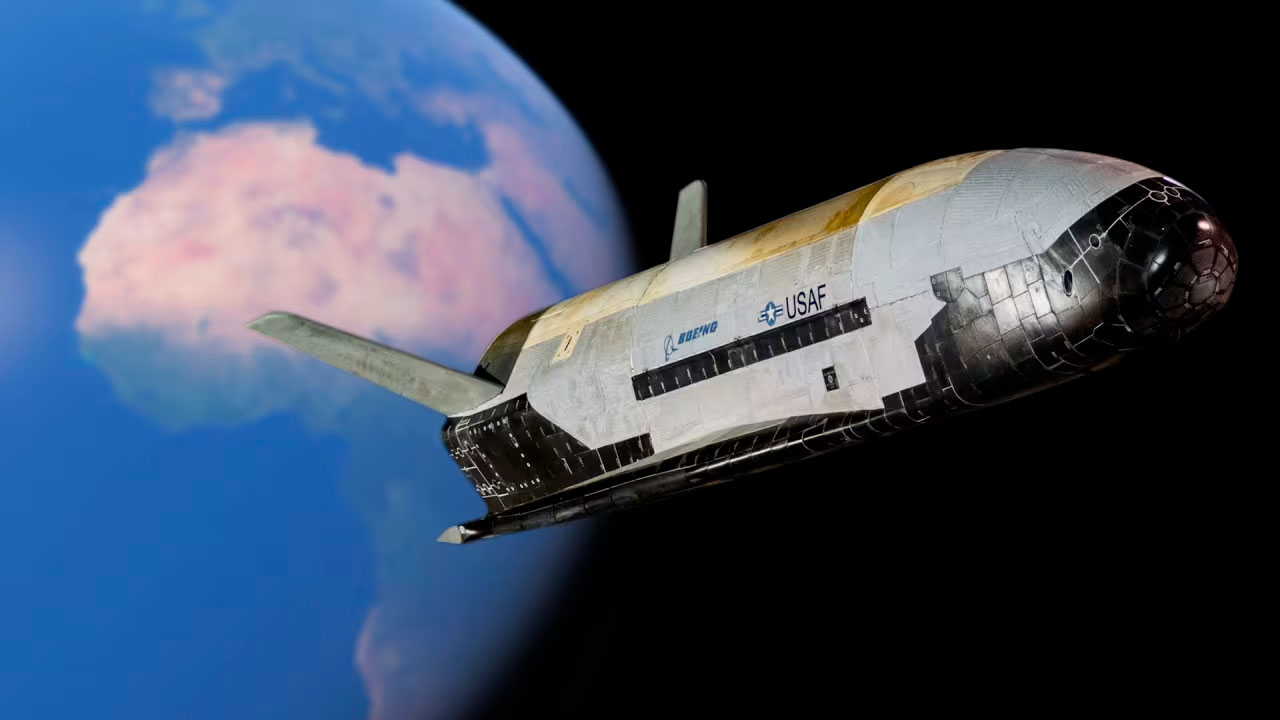




The integration of the cold-war era Peacekeeper gyroscope (originally developed for the MX Peacekeeper missile’s Advanced Inertial Reference Sphere, or AIRS) completes the Capsule Corp navigation infrastructure. It provides an ultra-precise, non-GPS-dependent inertial reference baseline that functions perfectly whether deep underwater or in a high-radiation low-Earth orbit.
1. The Peacekeeper Gyroscope Integration
- Floatation and Precision: The AIRS-derived gyroscope utilizes a beryllium sphere floated in a fluorocarbon fluid. Because it has no mechanical gimbals, it eliminates "gimbal lock" entirely during rapid, multi-axis trans-atmospheric rolls or tight underwater maneuvers.
- Sovereign Positioning: It measures acceleration and orientation changes with absolute accuracy. This allows the capsule to navigate indefinitely without relying on external GPS signals or satellite uplinks that could be jammed or spoofed by adversaries.
2. Upgraded Logic Interconnect Matrix
To incorporate the Peacekeeper gyro's hyper-precise analog drift data into the modular architecture, the telemetry loop maps directly to the voltage logic framework:
- Analog Drift Mapping: The raw drift and acceleration signals from the floated sphere are instantly down-converted into the native 0.0V to 1.0V hexadecimal voltage map. Each tiny physical shift translates to a precise 0.0625V state increment, bypassing modern computer processing lag entirely.
- UNIVAC IX Real-Time Vector Math: These ultra-low-latency voltage steps are fed straight into the UNIVAC IX backplane, where three-word stacking handles the incoming telemetry vectors at 36-decimal place accuracy to calculate orbit tracks or submarine drift correction profiles without truncation errors.