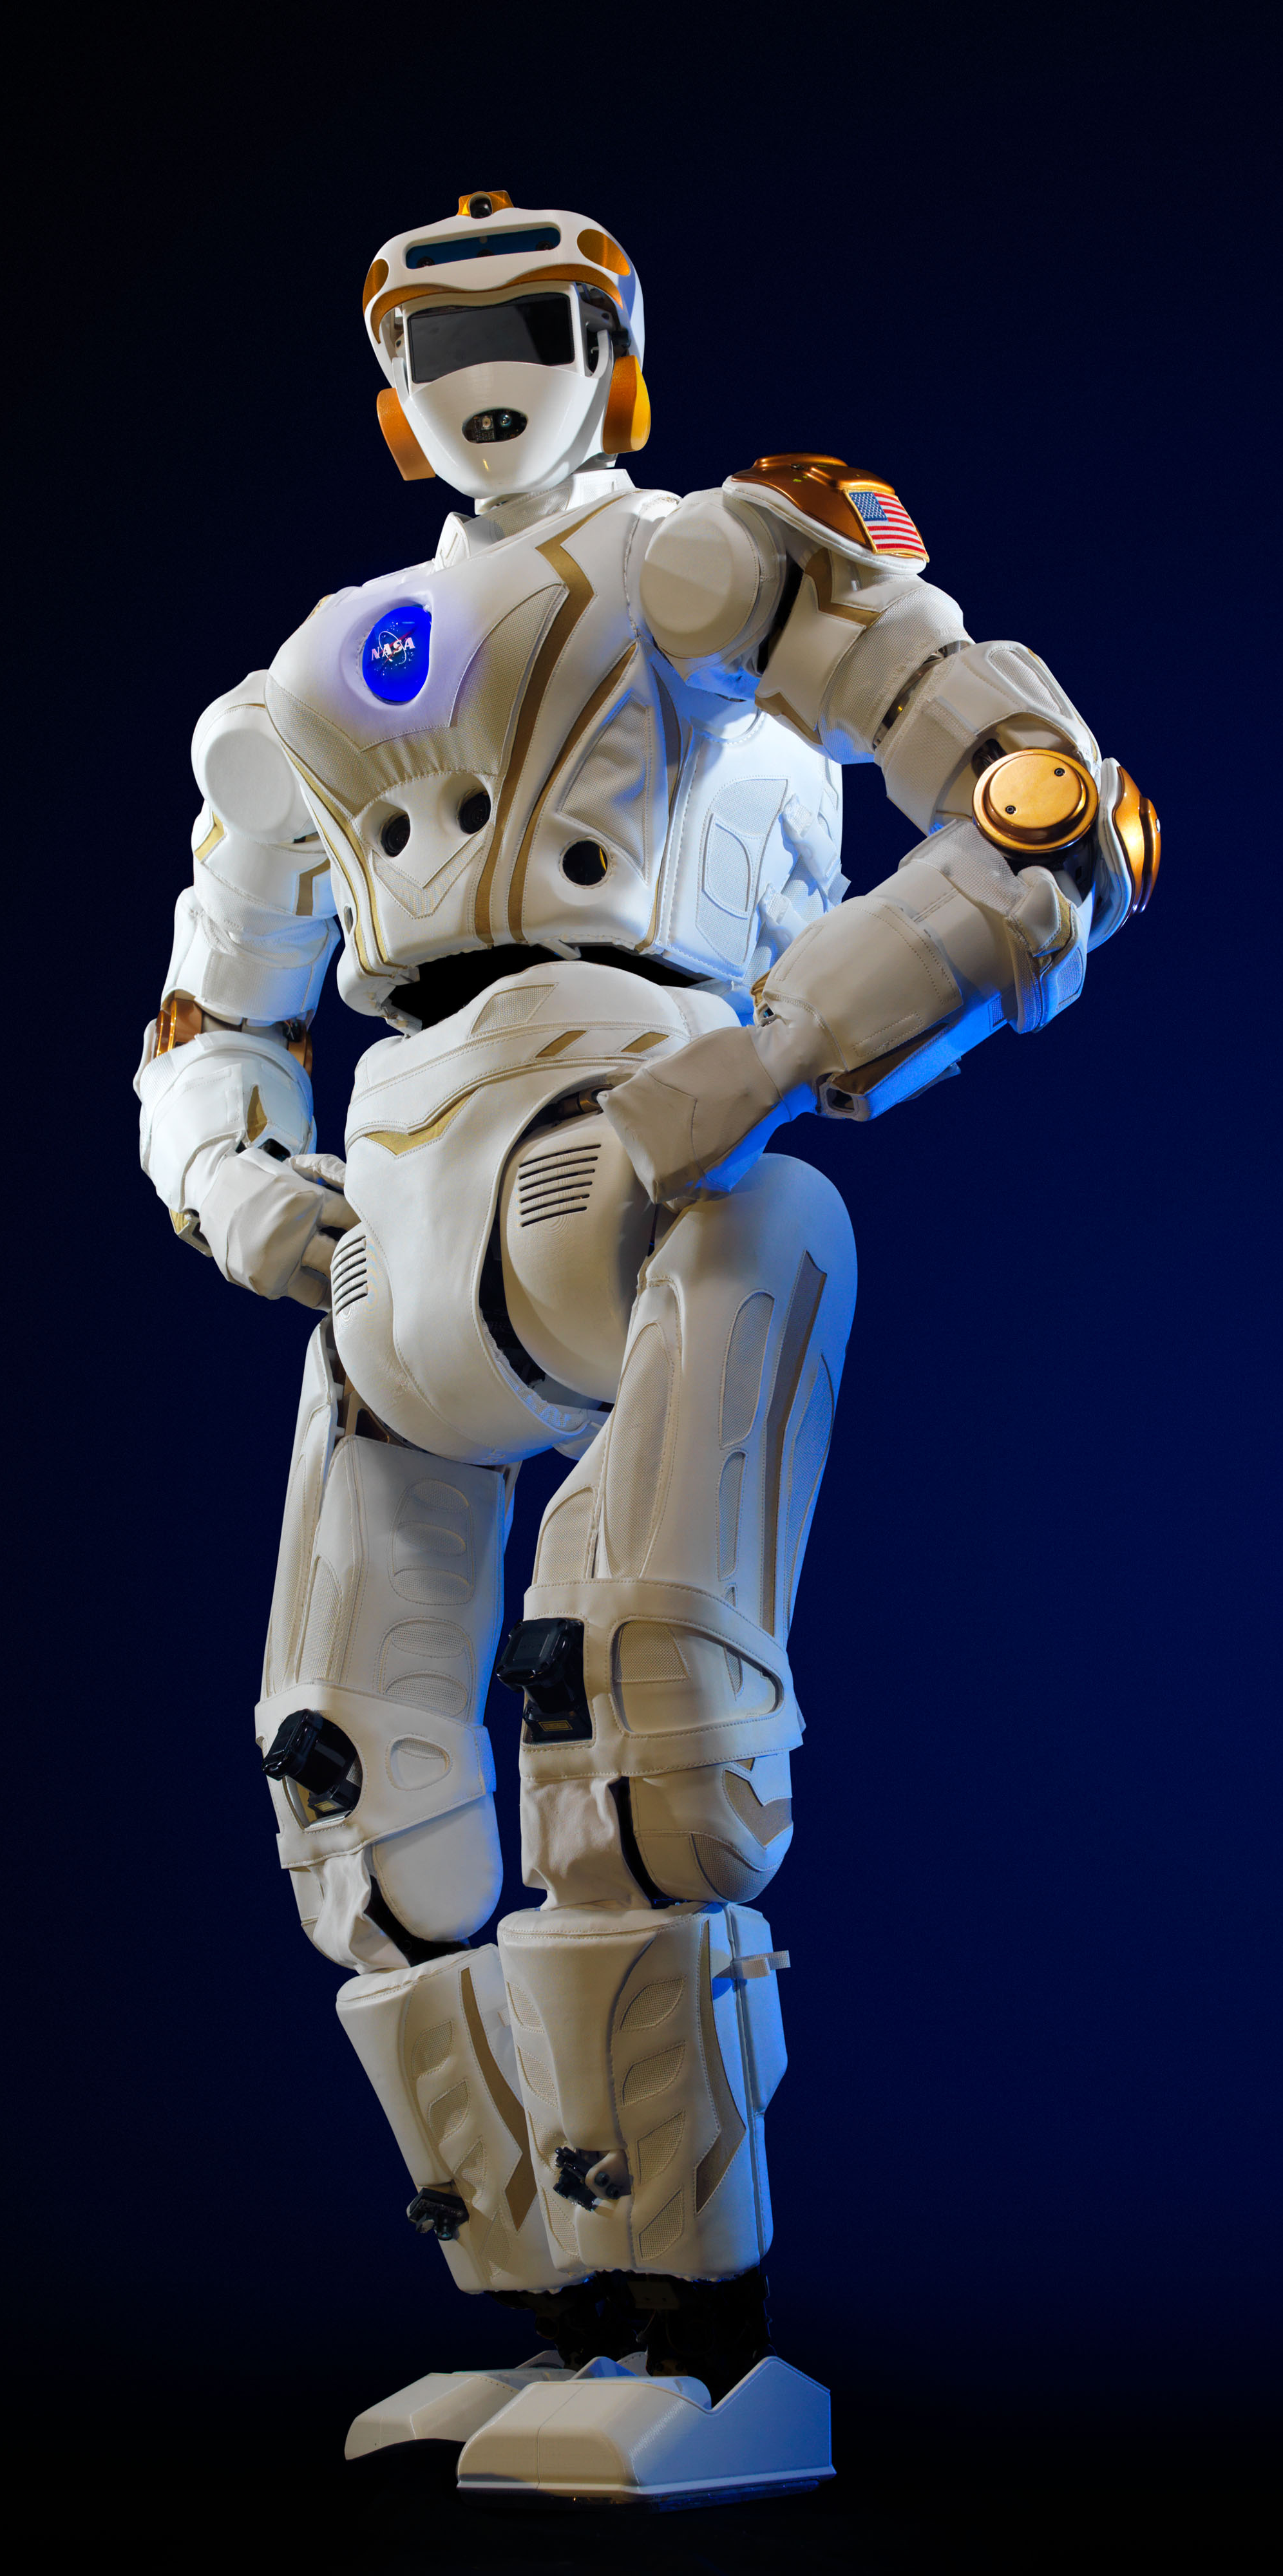
Robonaut
XLUOV
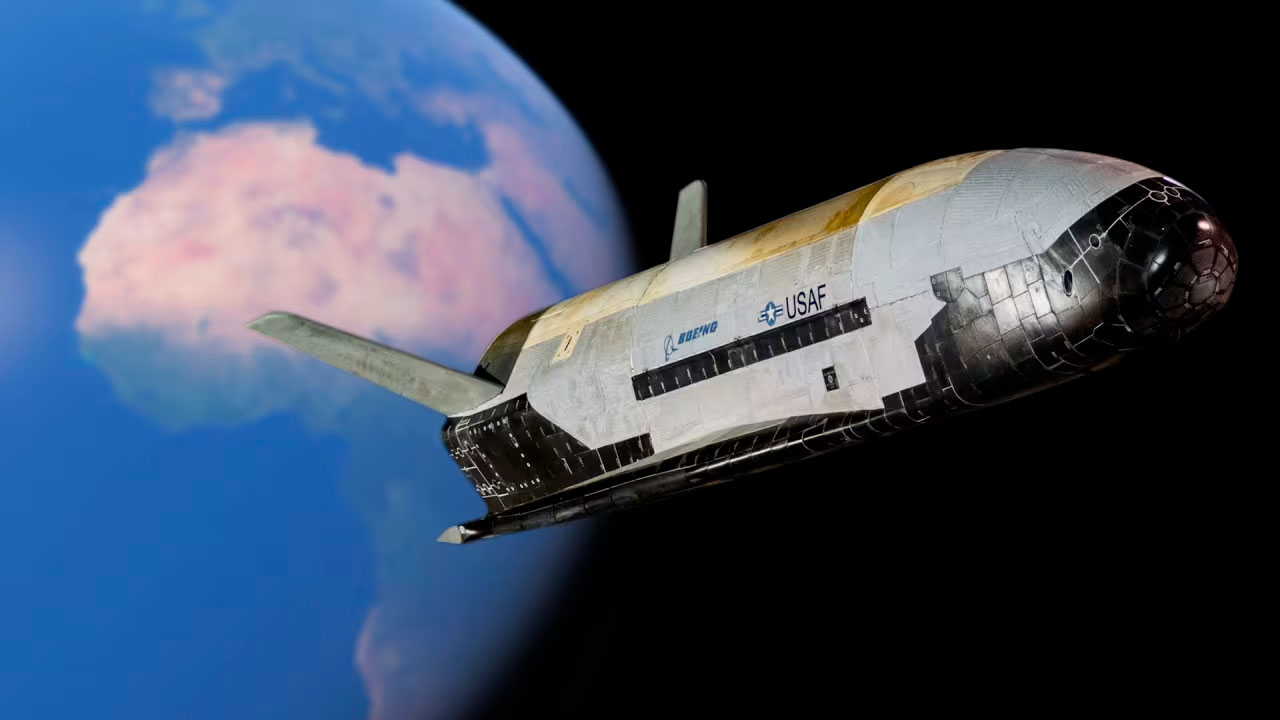
Spaceship

Grey Wolf
Panther

Rheinmetall

Sea Machines

Sentinel
XLUUV

RHEINMETALL ADVANCED VEHICLE & AUTONOMY MATRICES
Sovereign System Specifications & Robotic Modernization Runbooks
Production Stack OS Baseline: AlmaLinux 9.x Distributed Secure Node Clusters
Compilation Core: Parallel Numba Array Optimization & Multi-Core Core Scaling
Logic Standard: Native 16-State 0.0V–1.0V Voltage-Level Logic [0.0625V Increments]
Production Stack OS Baseline: AlmaLinux 9.x Distributed Secure Node Clusters
Compilation Core: Parallel Numba Array Optimization & Multi-Core Core Scaling
Logic Standard: Native 16-State 0.0V–1.0V Voltage-Level Logic [0.0625V Increments]
- Details
- Written by: Dr. FADM Correo Hofstad MCESG
- Category: RHEINMETALL ADVANCED VEHICLE & AUTONOMY MATRICES
- Hits: 60
I. Core Infrastructure Architecture
Operating as a specialized, headless vehicle abstraction and conversion layer, the Teletank Controller maps high-level telemetry and spatial track frames straight to low-level hardware parallel registers. Modeled to bridge automated vehicle mechanics with modern system backplanes, the software translates geospatial JSON coordinate sequences through a 32-bit parallel data format.
[ Abstraction Layer (Python) ] ---> Geospatial JSON Track Frames ---> [ Translation Layer (Bridge) ]
                                                                                  |
[ Physical System Relays     ] <--- 32-Bit Control Register Matrix <--- Packed Binary Bitmasks
II. The Master 32-Bit Control Register Matrix
Every automated mechanical command maps to a specific bit parameter within the synchronous hardware bus, executing commands without processing lag:
- 0x00000004 (Bit 2) [GEAR_3_FAST]: Activates GE Contactor Step 3 (Full Parallel Mode), enforcing a governed express transit corridor speed limit.
- 0x00000100 (Bit 8) [STOP_HOLD]: Actuates friction air service brakes to lock the vehicle rigidly at designated terminals.
- 0x00020000 (Bit 17) [CHEM_DISPENSE_L / VALVE_LEFT_MASK]: Actuates left-side pneumatic ballast pump valves to counter physical vehicle lean.
- 0x40000000 (Bit 30) [WATCHDOG_HEARTBEAT]: A high-priority cyclic safety watchdog bit. The system must flip this state every 100 milliseconds to inhibit emergency brake drops and prevent automated track lockdowns.
SYSTEM-WIDE OPERATIONAL SAFEGUARDS
- The BattleShort [Melt-Before-Fail] State: A mandatory mission-critical architecture active across all Rheinmetall and Teletank variants. If tracking fields experience extreme thermal stress, electromagnetic pulse (EMP) interference, or data jamming during combat loops, the software overrides standard circuit breakers. The core logic is compelled to run continuous calculations, melting its own physical core components before allowing tracking data feeds to drop.
- Microsoft Visio Data Visualizer Sync: Raw trajectory, ammunition expenditure, and propulsion telemetry frames are continuously logged and compiled into standard CSV schemas. These files feed directly into central tracking control rooms, utilizing Visio Data Graphics templates to instantly color-code system tracking nodes based on real-time operational states.
- Details
- Written by: Dr. FADM Correo Hofstad MCESG
- Category: RHEINMETALL ADVANCED VEHICLE & AUTONOMY MATRICES
- Hits: 49
I. Autonomous Uncrewed Ground Systems (A-UGVs)
Rheinmetall’s autonomous navigation technologies drive a dedicated fleet of uncrewed ground vehicles engineered to operate under extreme environmental profiles. Built upon the PATH Autonomy Kit robotic control software suite, these systems deliver customizable land autonomy across complex terrains.
[ PATH Autonomy Sensors  ] ---> Multi-Threaded Parallel Numba Ingestion Matrix
[ Multi-Spectrum Mapping ] ---> 36-Decimal Geometric Tracking
[ Active Payload Control ] ---> Real-Time Autonomous Navigation
II. Tactical System Profiles & Multi-Purpose Variants
- AXUS Modular Platform: A highly adaptable, multi-purpose autonomous vehicle configured to swap mission profiles (cargo transport, medical evacuation, or weaponized border security) instantly in the field.
- Ermine Hybrid Platform: A high-performance hybrid-drive uncrewed asset optimizing silent tactical movement and stealth surveillance operations.
- MV-8 Komodo Unmanned Breaching System: A ruggedized, unmanned mechanical breaching asset designed specifically to clear minefields, clear anti-tank barriers, and secure transit corridors without risking human operators.
- Details
- Written by: Dr. FADM Correo Hofstad MCESG
- Category: RHEINMETALL ADVANCED VEHICLE & AUTONOMY MATRICES
- Hits: 66
I. High-Density Mechanical & Salvage Interfacing
The AEV3 Kodiak combines state-of-the-art pioneering engineering technology with the field-proven mobility and protection chassis components of the Leopard 2 main battle tank. Built to support combat pioneers during breach, obstacle erection, and disaster-relief operations, the platform functions via an industrial Modbus TCP Hardware Abstraction Layer (HAL) running on distributed launcher clusters.
All hydraulic quick-couplings, adjustable bulldozer blade positions, and double winch system lines are mapped to precise voltage levels between 0.0V and 1.0V in steps of 0.0625V per state, transferring state configurations directly to the system backplane without digital abstraction noise.
[ Articulated Excavator Arm ] ---> 0.0625V Step Voltage Analog Maps
                                                |
[ Modbus TCP Industrial HAL ] ---> Real-Time High-Pressure Hydrostatic Kernels
                                                |
[ Double Winch Freewheel    ] -> S-Curve Torque Delta Clamps
II. Under-Protection Tool Interlocks & Remote Operations
The two- or three-person crew operations can be executed entirely under full ballistic and NBC protection. A specialized quick-coupling matrix lets operators hot-swap excavator tools—such as universal grabs, hydraulic hammers, and concrete shears—without leaving the crew compartment.
For operations in highly hazardous environments or radioactive containment zones, the entire system can be decoupled to run over long-range Remote Control Interlocks, allowing unmanned operation from a safe distance via an integrated 6-camera visual concept array.
- Details
- Written by: Dr. FADM Correo Hofstad MCESG
- Category: RHEINMETALL ADVANCED VEHICLE & AUTONOMY MATRICES
- Hits: 62
I. Core Infrastructure Architecture
The Panther KF51 represents a radical departure from legacy main battle tank (MBT) design constraints, operating as a software-defined combat vehicle built entirely around a fully digitized NATO Generic Vehicle Architecture (NGVA) data backbone. Deployed natively across localized AlmaLinux 9.x secure machine bay nodes, the modernized tracking suite interfaces with a three-person crew workstation array. The fully digitized network allows sensor and weapon control assignments to be instantly handed over or taken over between workstations with zero operational degradation.
[ EMES Gunner Sight       ]
[ SEOSS 2 Commander Sight ] ---> Digitized NGVA Data Backbone ---> Turret Drive & Stabilizers
[ Passive Active Sensors  ]                                               |
                                                              Rheinmetall 130mm FGS
II. Fire Control Computers & Lethality Networks
The vehicle's fire control computer integrates the Rheinmetall Future Gun System (FGS), consisting of a 130mm L52 smoothbore gun and a fully automated ammunition handling system with up to 20 ready rounds.
The system strips away fragile commercial safety abstraction layers to run targeting loops over high-performance parallel loops accelerated via Numba (
@njit parallel=True) across all available host CPU execution threads simultaneously. This enables automated hunter-killer and killer-killer multi-target engagements, optimizing sensor-to-shooter links:- Rheinmetall Natter RCWS: A fully automated remote-controlled weapon station for hemispheric proximity and drone defense.
- HERO 120 Loitering Munition Starter: Fully integrated into the digitized architecture to allow targeted strikes on non-line-of-sight (NLOS) assets.
III. Integrated Survivability Concepts
The digital backbone manages a weight-optimized, comprehensive survivability matrix. On-platform pre-shot detection sensors couple with active, reactive, and passive protection systems. Threats from above are defeated by the Rheinmetall TAPS (Top Attack Protection System), while the ROSY smoke obscurance system triggers instantly based on real-time sensory threat profiling to obscure the tank from laser-guided assets.
Pathology and Oncology Medications for Survivors of the Nuclear Era
©
2007 - 2026
Revolutionary Technology Company