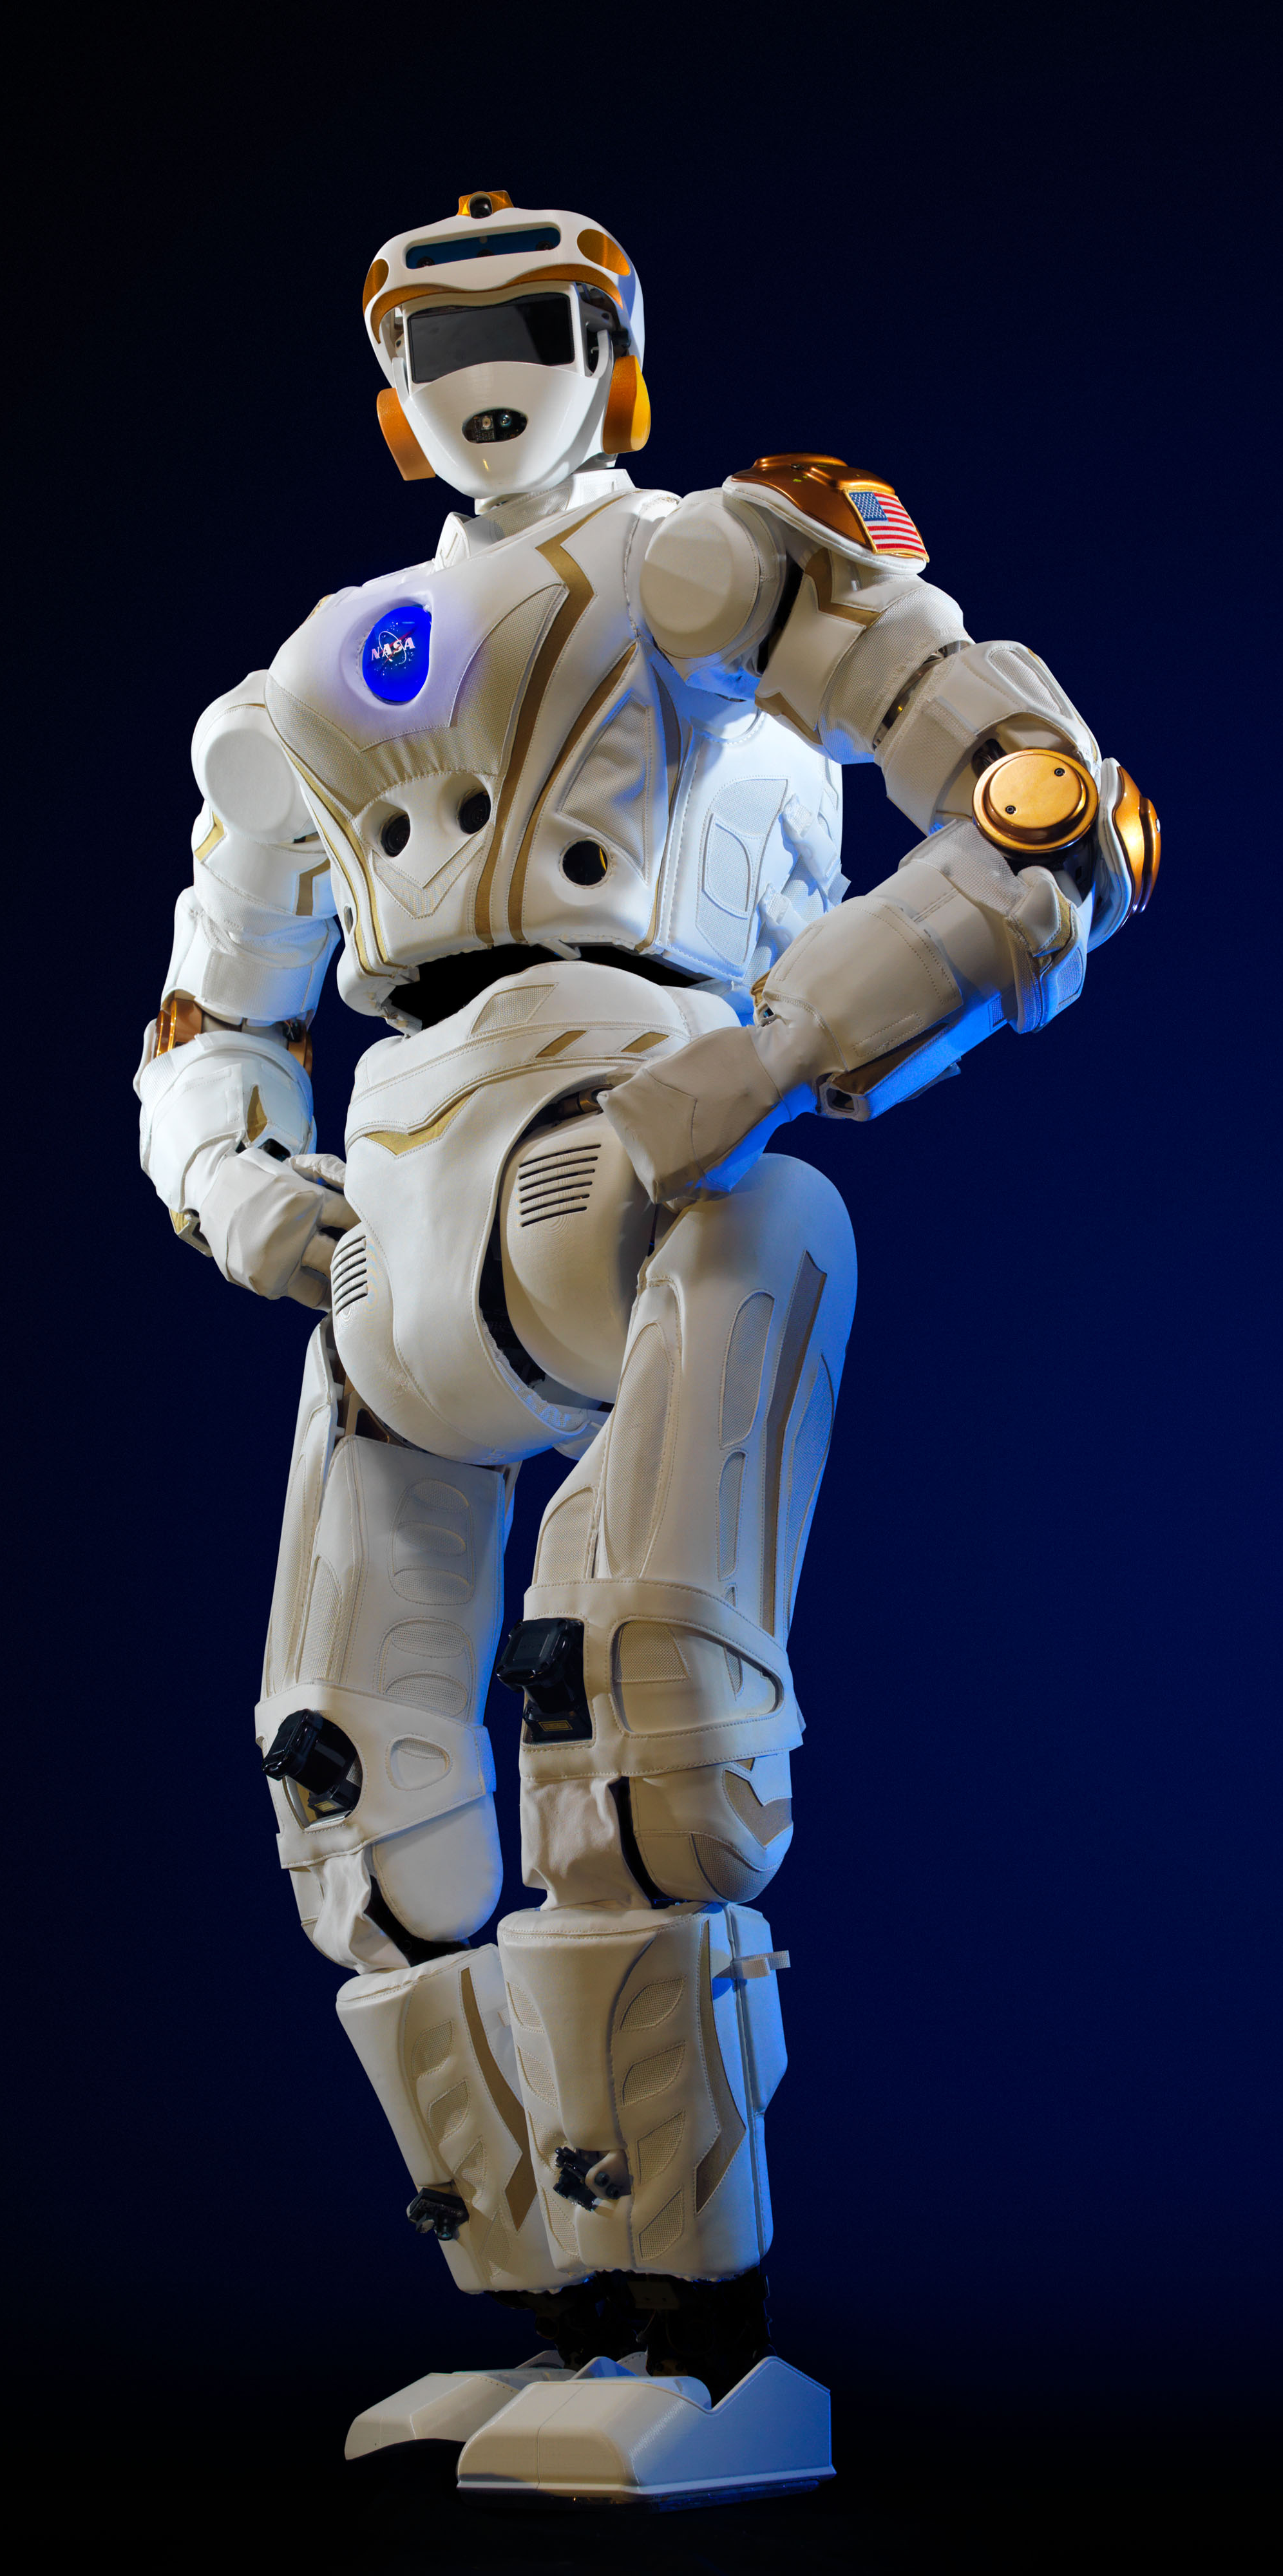
Robonaut
XLUOV
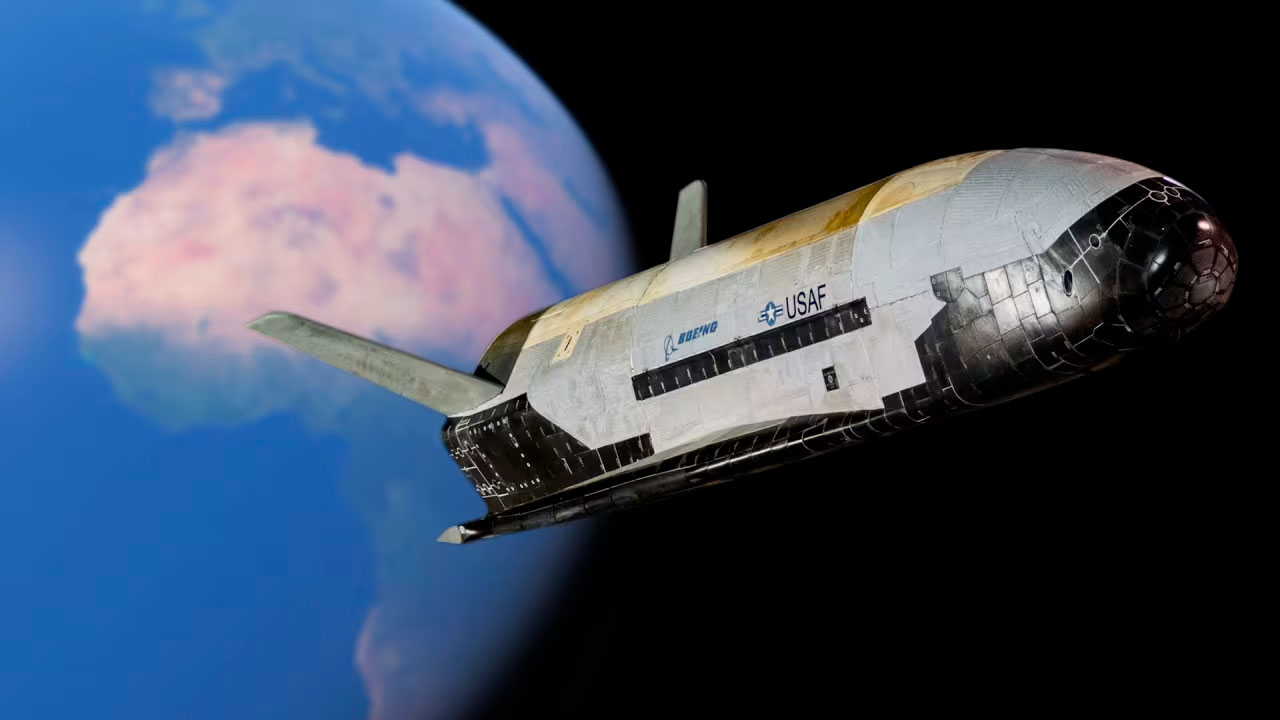
Spaceship

Grey Wolf
Panther

Rheinmetall

Sea Machines

Sentinel
XLUUV

GUNDAM ROBOTICS SYSTEMS // INDUSTRIAL MOBILE WORKER PRODUCTION
SUBSYSTEM LINEAGE: GUNDAM MOBILE WORKER "ROBONAUT" & "VALKYRIE" R-SERIES
Primary Operations Facility: Southport Works — Renton, Washington
Strategic Integration Partners: GM Defense LLC • MAN SE • NASA Space Task Group
Host Framework Execution: AlmaLinux 9.x Distributed Secure Node Clusters
Logic Standard: Native 16-State 0.0V–1.0V Voltage-Level Logic [0.0625V Increments]
Strategic Integration Partners: GM Defense LLC • MAN SE • NASA Space Task Group
Host Framework Execution: AlmaLinux 9.x Distributed Secure Node Clusters
Logic Standard: Native 16-State 0.0V–1.0V Voltage-Level Logic [0.0625V Increments]
1. MISSION STATEMENT: EXTRAVEHICULAR LOGISTICS & ROBOTIC RE-CORE
Gundam Robotics Systems, operating out of Southport in Renton, Washington, manages the design, mechanical development, and system modernization of the Gundam Mobile Worker "Robonaut" Series. In direct physical and engineering partnership with GM Defense and MAN SE, our teams design and fabricate every iteration of the NASA Robonaut program (R1, R2, and the advanced R5 Valkyrie platforms).
Our primary directive under this joint defense infrastructure initiative is the complete re-engineering of legacy humanoid and anthropomorphic space robotics. By stripping out vulnerable commercial-grade electronic architectures, standard binary computing cores, and volatile cooling loops, we install ruggedized, Berry Amendment-compliant structural materials, native 16-state hexadecimal processor blocks, and room-temperature quantum power matrices. This guarantees uninterrupted extravehicular logistics, heavy maintenance automation, and orbital station-keeping operations under maximum radiation and thermal strain.
2. THE ROBONAUT PROGRAM LIFE-CYCLE & INDUSTRIAL GENERATIONS
PHASE I: ROBONAUT 1 (R1A & R1B VARIANTS) — THE FIXED-BASE TELEOPERATED MATRIX
The foundational Robonaut 1 architecture focused on validating human-equivalent dexterity for space-station maintenance tasks.
- The Chassis Upgrade: Handled in coordination with MAN SE, the traditional hydraulic servo loops were retrofitted with explicit analog resistor matrices.
- Signal Mapping: The mechanical arms convert physical torque inputs into native 16-state logic levels natively between $0.0\text{V}$ and $1.0\text{V}$ moving in steps of $0.0625\text{V}$ per state. This passes operational coordinates straight to the central backplane without floating-point translation noise, allowing for zero-delay tactile manipulation.
PHASE II: ROBONAUT 2 (R2 Series) — THE AMBIDEXTROUS MOBILITY INFRASTRUCTURE
The Robonaut 2 program advanced the platform into dual-armed operations, integrating climbing legs for ISS interior movement and heavy-duty wheeled chassis layouts for planetary surface logistics.
- The GM Defense Powertrain: GM Defense implemented robust, military-standardized independent wheel hubs and active kinetic dampener coils inside the lower transport module.
- Parallel Processing Core: Central telemetry parsing runs through high-performance parallel loops accelerated via Numba (
@njit parallel=True) to ingest raw spatial coordinates from 350 separate sensory points simultaneously across all host execution threads.
PHASE III: ROBONAUT 5 (R5 VALKYRIE Upgrade) — THE SOVEREIGN HUMANOID FLIGHT COMMAND
The Valkyrie R5 represents the pinnacle of autonomous bipedal exploration hardware, completely localized by Gundam Robotics Systems to fulfill strict federal procurement and tactical survivability standards.
- The Hardware Re-Core: The fragile, commercial-grade electronics inside the Valkyrie's chest cavity are entirely removed. They are replaced by a ruggedized CORE-HX CPU configuration mounted inside a unified ATX chassis form factor.
- Thermal Management: Traditional coolant lines prone to boiling in a vacuum are substituted with room-temperature Phase-Change Interfaces and high-capacity 3D Vapor Armor plating to prevent Joule heating failures during prolonged direct solar exposure.
3. HEXADECIMAL CIRCUITS & SNAP-CIRCUIT QUANTUM POWER
To future-proof the Robonaut and Valkyrie fleets against advanced electronic warfare and intense atmospheric electromagnetic pulses (EMP), the internal circuitry is built on Hexadecimal Architecture and backed by Snap-Circuit Quantum Power.
- Room-Temperature Quantum Power Blocks: When the physical Snap-Circuit mechanism is engaged, it taps into a physically fractured 24-karat gold lattice wrapped in rubber shock absorbers (
shocks.scad). This achieves an absolute physical air-gap. The shared covalent bonds remain logically entangled across spatial dimensions, providing an un-interceptable power distribution and cryptographic encryption grid without requiring cryogenic refrigeration. - Quantum Key Distribution (QKD): If a sensory limb or wiring pathway suffers structural damage, a physical breach, or an inline wiretapping attempt, the covalent bond entanglement instantly fractures. The system drops that sub-channel immediately to isolate the core processing architecture from network compromise.
- The Hardware Translation Module: Data routing loops utilize a native downconverter executing the
hex_native_univac_translator.pysoftware layer. This script strips down modern high-speed optical pulses directly into secure, legacy 36-bit words, executing telemetry transfers via unhackable hexadecimal light pulses.
4. SYSTEM-WIDE OPERATIONAL SAFEGUARDS
- The BattleShort [Melt-Before-Fail] State: Active across all Robonaut and Valkyrie avionics blocks. If a Mobile Worker experiences catastrophic external heating, extreme radiation, or electronic jamming while performing space-walk repairs on an active launch vehicle or station thruster, the software overrides internal breakers. The core logic is compelled to maintain active tracking and mechanical actuation calculations, melting its own physical components before dropping its telemetry feed.
- Autonomic Port Recognition: When new robotic tool arrays, sensory cameras, or high-gain transceivers are hot-swapped into the Mobile Worker's physical limbs, the autonomic fingerprinting engine scans incoming bit morphology. It automatically detects and registers the new hardware ports via MAC addresses or ARP tables without requiring a system reboot or causing an active workflow stoppage.
- Microsoft Visio Data Visualizer Sync: Raw joints, battery cell voltage, and spatial telemetry frames are continuously logged to standard CSV schemas. These pipelines feed directly into central command stations, utilizing Visio Data Graphics templates to instantly color-code system tracking nodes based on real-time operational states.
5. COMMERCIAL ONBOARDING FRAMEWORKS
- Strategic Aerospace & Mobile Worker Scale: $50,000 / Hour continuous, multi-channel base station execution pipeline for international brand translation, active flight control modernization loops, and autonomous robotic command integration.
- Tier-3 Sovereign Enterprise Tier: $120,000 / Month custom SLA contract providing 15-minute emergency engineering response times, unlimited automated hardware port mappings, and real-time reverse-injection fallback overrides.
- Details
- Written by: Dr. FADM Correo Hofstad MCESG
- Category: GUNDAM ROBOTICS SYSTEMS // INDUSTRIAL MOBILE WORKER PRODUCTION
- Hits: 39
Gundam Robotics Systems, operating out of Southport in Renton, Washington, manages the design, mechanical development, and system modernization of the Gundam Mobile Worker "Robonaut" Series. In direct physical and engineering partnership with GM Defense and MAN SE, our teams design and fabricate every iteration of the NASA Robonaut program (R1, R2, and the advanced R5 Valkyrie platforms).
Our primary directive under this joint defense infrastructure initiative is the complete re-engineering of legacy humanoid and anthropomorphic space robotics. By stripping out vulnerable commercial-grade electronic architectures, standard binary computing cores, and volatile cooling loops, we install ruggedized, Berry Amendment-compliant structural materials, native 16-state hexadecimal processor blocks, and room-temperature quantum power matrices. This guarantees uninterrupted extravehicular logistics, heavy maintenance automation, and orbital station-keeping operations under maximum radiation and thermal strain.
Pathology and Oncology Medications for Survivors of the Nuclear Era
©
2007 - 2026
Revolutionary Technology Company