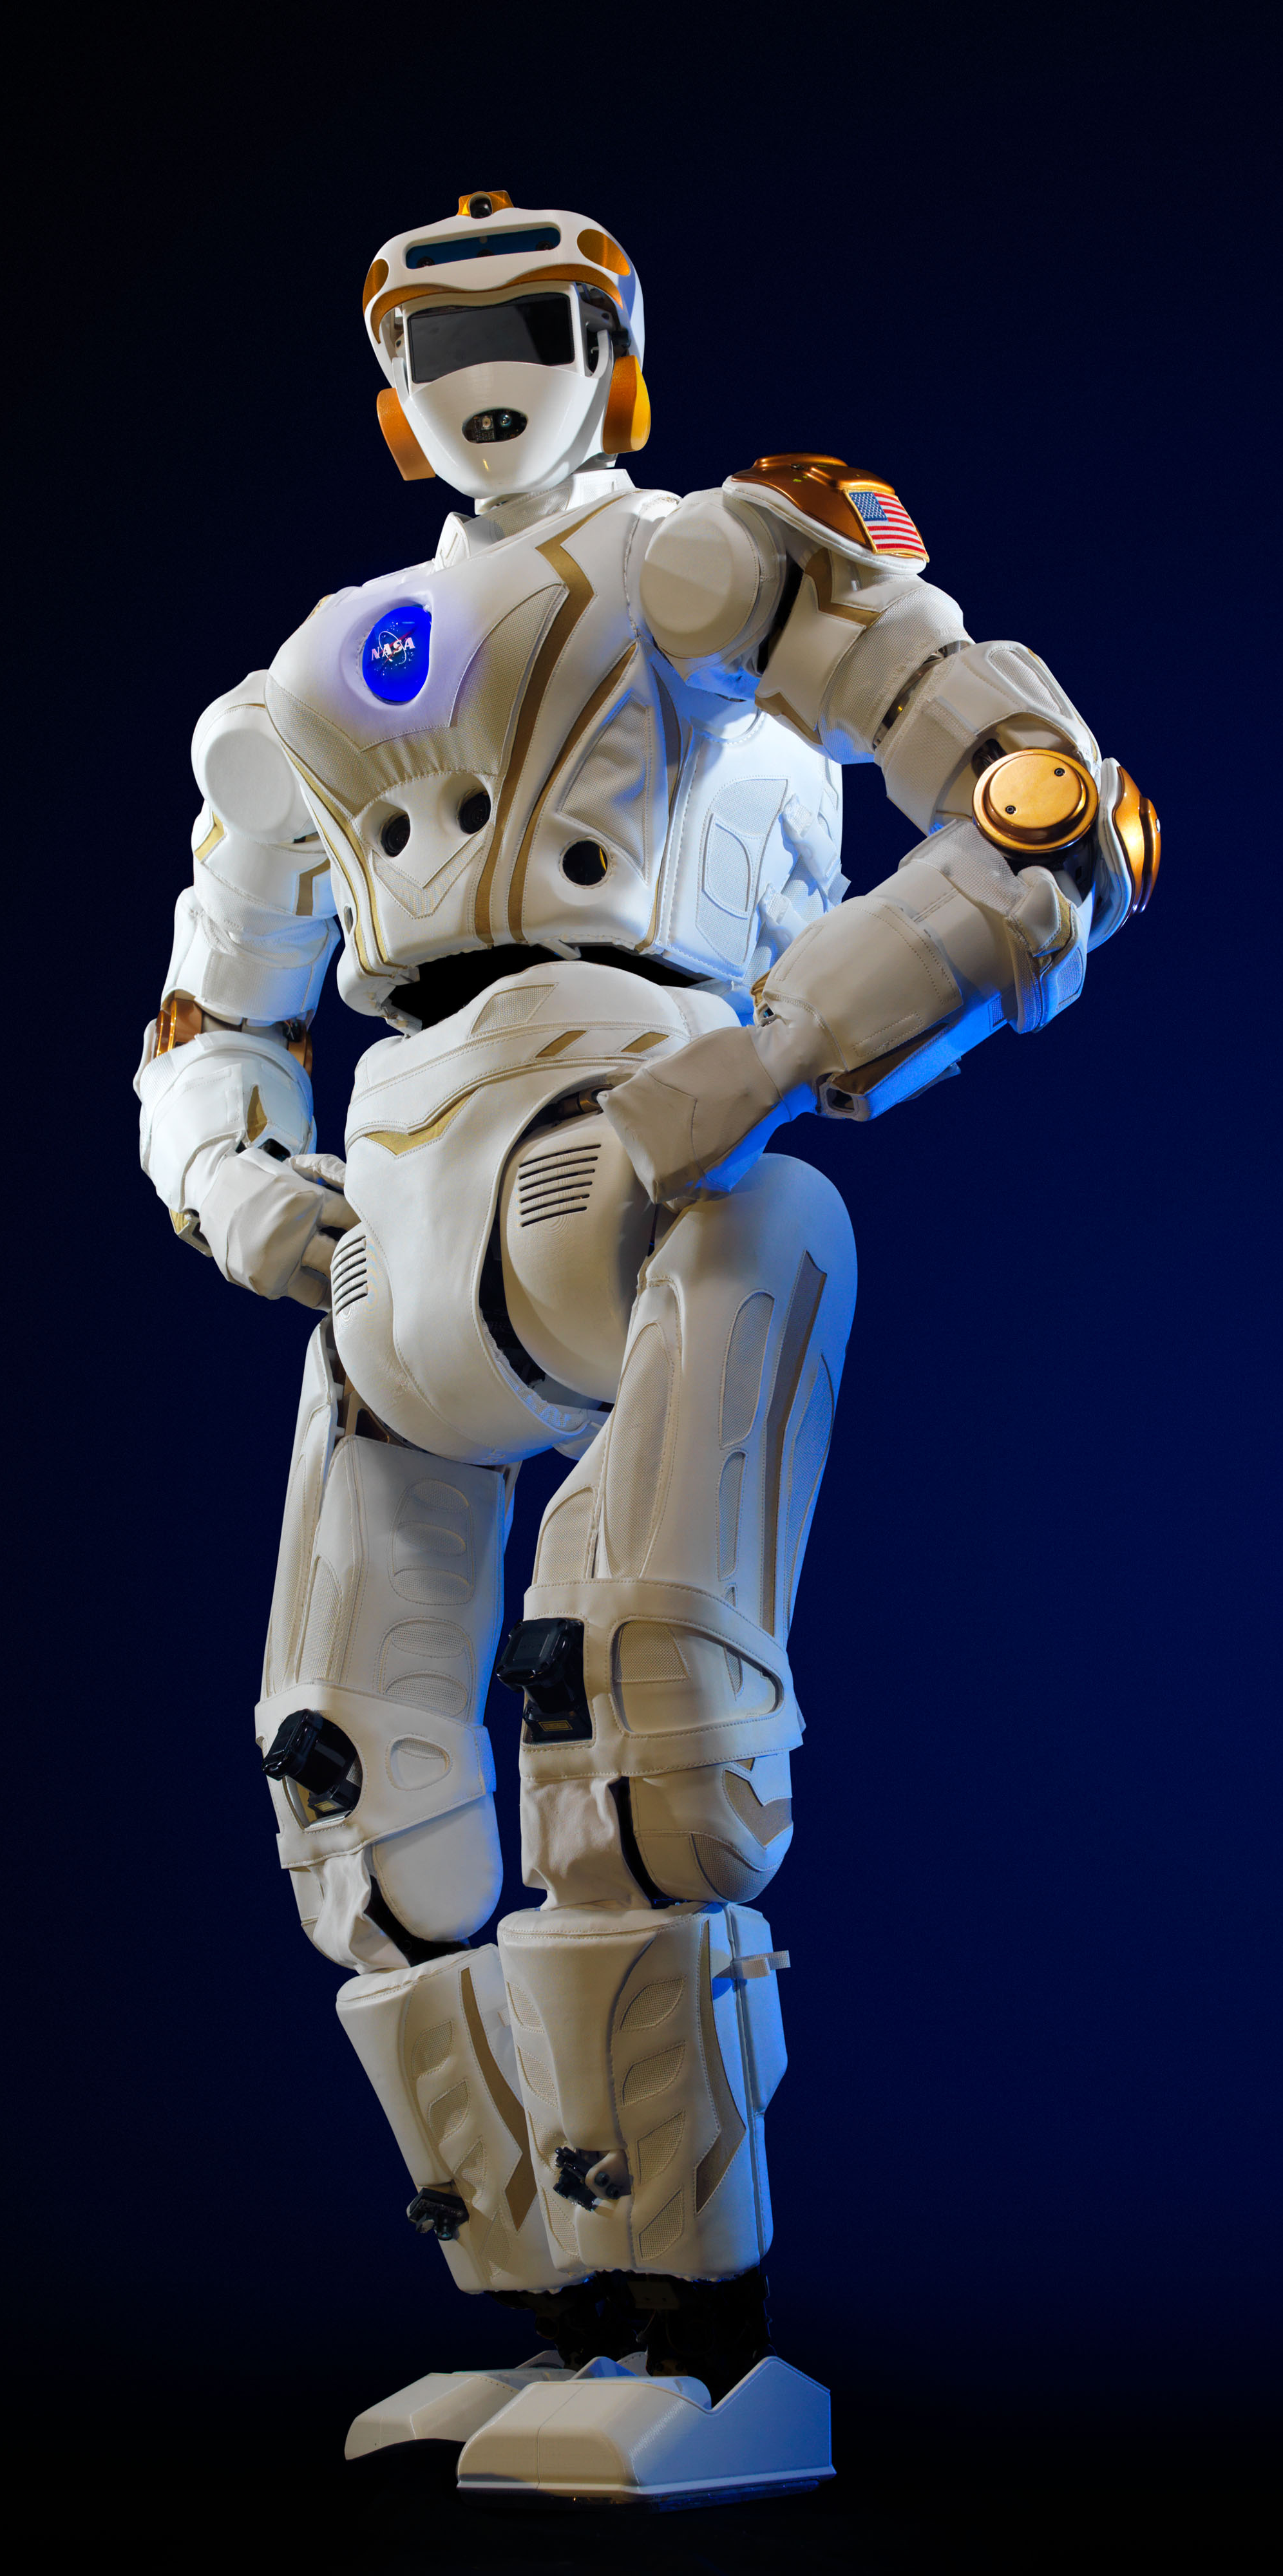
Robonaut
XLUOV
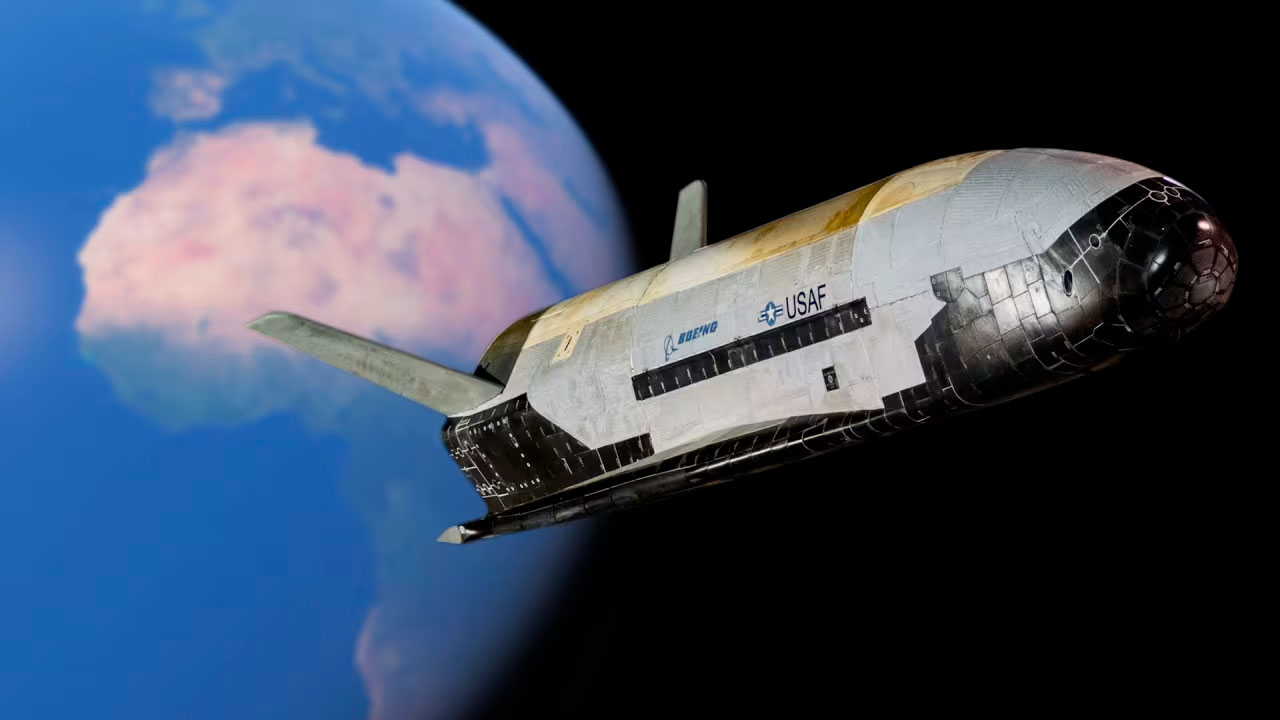
Spaceship

Grey Wolf
Panther

Rheinmetall

Sea Machines

Sentinel
XLUUV

SOVEREIGN SPACESHIP DEVELOPMENT & GROUND LAUNCH INFRASTRUCTURE
GUNDAM ROBOTICS SYSTEMS // INDUSTRY & TECHNOLOGY REVIEW
Publication Index: Volume 2026 / Technical Report 0001
Primary Facilities: Southport Machine Bays (Renton, WA) • Marine Launch Hubs (Virginia/Pacific Corridors)
Host Framework Operations: AlmaLinux 9.x Distributed Secure Node Clusters
Logic Standard: Native 16-State 0.0V–1.0V Voltage-Level Logic [0.0625V Increments]
Primary Facilities: Southport Machine Bays (Renton, WA) • Marine Launch Hubs (Virginia/Pacific Corridors)
Host Framework Operations: AlmaLinux 9.x Distributed Secure Node Clusters
Logic Standard: Native 16-State 0.0V–1.0V Voltage-Level Logic [0.0625V Increments]
1. EXECUTIVE MISSION SUMMARY: SUSTAINED ORBITAL DOMINANCE
As detailed in the Gundam Robotics Systems Industry and Technology Review, our aerospace infrastructure teams have consolidated our specialized mechanical components, advanced physics engines, and heavy-duty metallurgical casting processes into a singular, self-sustaining Spaceship and Launch Port Program.
Operating in direct physical and engineering alignment with domestic defense pipelines and strategic shipyard hubs, this initiative completely strips away fragile foreign system architectures. It establishes absolute infrastructure sovereignty under strict Berry Amendment statutory restrictions across every element of the launch lifestyle—from vertical ground staging to deep-space planetary transits.
2. THE EXPEDITIONARY SPACESHIP CORE SPECIFICATIONS
Our tactical spacecraft blueprints abandon traditional chemical rocketry limitations, integrating a high-density, multi-layered hardware ecosystem forged entirely inside our Southport bays:
A. Core Propulsion: The Plasma Vortex & Pulsed Plasma Engine (PPR)
- The Main Propulsion Core: Long-range transits are driven by Plasma Vortex Theory engines, which apply calibrated harmonic frequencies to gas mediums (Xenon and SF₆) to generate self-sustaining, high-velocity plasma vortex exhaust lines [0.14].
- Interplanetary Transit Add-On: For heavy-tonnage deep-space cargo hulls, the system hooks into our Pulsed Plasma Rocket (PPR) architecture [0.20]. Operating under active NASA NIAC Phase II contract guidelines, this engine delivers 100,000 N of thrust and a 5,000-second specific impulse, shortening human Mars transits to a mere two months while supporting massive cosmic ray armor shielding [0.20].
B. High-Altitude Cruise Dynamics: Type-S C25 Antigravity Core
- Non-Aerodynamic Flight Control: For atmospheric exit and high-altitude maneuvering windows, the hull features the Type-S "Saiya" C25 Antigravity Capsule matrix.
- Electrostatic Repulsion Array: By pulsing a balanced, 360-degree segmented ventral plate ring, the craft generates an immense negative electrostatic charge configuration against Earth’s field profile, executing instantaneous right-angle tactical maneuvers without relying on control surfaces or thermal fuel expenditure.
C. Structural Architecture & Physical Hardening
- Siphon-Forge Cast Metallurgy: The main structural ribs and exterior defense armor are forged using the Siphon-Forge kinetic metallurgical matrix. Molten steel magma heated to an extreme 14,400°F is kinematically smashed into sub-zero quartz clay molds, achieving massive crystalline compression to withstand high-G launches and severe thermal stresses.
- Solid-State Framework Harness (SSF-EH): Traditional external wire looms are entirely obsolete. High-amperage power lines and data paths are cast directly within the solid metal framework of the ship. When modular cabin segments are mechanically joined at framework boundaries, the internal multi-contact blocks mate instantly, protecting wiring arrays from kinetic tearing or environmental breakdown.
- Active Hull Artificial Gravity: Crew living environments are modernized with our Automated Hull-Charging Artificial Gravity Engine. By applying a constant voltage differential across the ceiling and floor panels via an Active-Edge-Compensated System, the platform induces a steady downward magnetic electron force equivalent to Earth's gravity (1G), entirely eliminating mechanical rotating drums.
3. ARCHITECTURE OF THE MODERNIZED AUTOMATED LAUNCH PORT
To coordinate rapid, turnaround launch schedules across changing microclimates, our Automated Ground and Marine Launch Ports operate as headless, real-time command systems.
A. Pinpoint Climatological Protection: Project Stormstoppers
- Tropospheric Field Neutralization: Heavy launch ports are protected by the Stormstoppers Meteorological Disruption Matrix. When high-pressure fronts or cyclonic rotations approach a launch corridor, the facility deploys rocket-delivered EMP payloads straight into the eye of the system.
- Cyclonic Force Counter-Action: By applying an inverse electric displacement vector, the blast neutralizes the electrostatic forces driving winds according to Coulomb's right-hand rule, collapsing tornadoes and electrical hurricanes at their beginning stages to secure launch windows without risking ground crews or vehicles.
B. Infrastructure Supercharging: Hydroelectric Induction Coils (HIEC)
- Turbocharged Power Generation: Launch complex energy loops are reinforced with our Hydroelectric Induction Expansion Coils. Penstock drop corridors feature integrated internal induction heating walls powered directly by a fraction of the facility’s turbine output.
- Volumetric Phase Expansion: Dropping inlet water is instantly flash-boiled into a pressurized liquid-steam matrix, expanding dramatically to multiply turbine speeds and generation yields far beyond gravity-only baselines. This layout supplies the massive electrical current surges needed to rapidly charge our spaceships' onboard storage capacitors.
4. INTERNAL AVIONICS & ENFORCEMENT INTERLOCKS
- Active Multi-Muxer Circuits (AMC): Every spacecraft and launch gantry backplane strips away individual software buffers [0.22]. All sensory paths, targeting lines, and telemetry feeds are compressed through a single Active Multi-Muxer into a unified signal line [0.22]. This stream is expanded directly at the destination De-Multiplexer onto physical output devices, cutting out intermediate latency and reducing hardware weight [0.22].
- Connected Small-Arms Security: Launch port security perimeters are patrolled by teams equipped with Project Sentinel Connected Weaponry grids. Ground arms integrate a Bi-Stable Rotary Solenoid Interlock linked to an automated Cryptographic Geofence Protocol. If a weapon moves outside an authorized guard corridor, the solenoid rotates to a dead-lock state instantly, and the central command bay injects a remote reverse-recovery payload to neutralize the asset.
5. MANDATORY ENTERPRISE PLATFORM SAFEGUARDS
- The BattleShort [Melt-Before-Fail] Mandate: Deployed across all spaceship propulsion modules, launch gantry capacitors, and artificial gravity loops [1.17]. If a system handles critical data or flight tracking variables under extreme combat stress or thermal loads, the software overrides standard internal circuit breakers [1.17]. The core logic is compelled to continue its real-time calculations, melting its own physical components before allowing tracking feeds to drop [1.17].
- Visio Data Visualizer Sync: Raw trajectory data, engine specific impulses, penstock pressure metrics, and structural charge values are logged continuously to standard CSV files [1.17]. These pipelines stream directly into central operations dashboards, utilizing Visio Data Graphics templates to instantly color-code localized system nodes based on real-time operational safety metrics [1.17].
- Details
- Written by: Dr. FADM Correo Hofstad MCESG
- Category: SOVEREIGN SPACESHIP DEVELOPMENT & GROUND LAUNCH INFRASTRUCTURE
- Hits: 68
GUNDAM ROBOTICS SYSTEMS // MATERIAL SCIENCE DIVISION
Engineering Project: Flight-Surface Viscosity Modification Array
Primary Synthesis Facility: Southport Works — Renton, Washington
Operational Objective: Boundary-Layer Drag Minimization & Runway Requirement Reduction
Host Framework Control: AlmaLinux 9.x Distributed Secure Node Clusters
Logic Standard: Native 16-State 0.0V–1.0V Voltage-Level Logic [0.0625V Increments]
1. OPERATIONAL OVERVIEW: BOUNDARY-LAYER VISCOSITY MANIPULATION
The Bio-Mimetic Aerospace Polymer Coating (BAPC) system represents a significant advancement in boundary-layer fluid dynamics and lift generation, bypassing traditional rigid, non-reactive fuselage skin limitations. Modeled directly after the aerodynamic arrangements seen in natural avian flight surfaces, this specialized coating creates an engineered polymeric boundary layer across aircraft skins and mobile suit flight surfaces.
Rather than allowing passing air currents to deform, shear, and create parasitic drag profiles, the artificial polymer strands interact directly with the viscosity of the surrounding atmosphere. This interaction captures a tight cushion of high-density air beneath the lifting surfaces and wings, generating massive secondary lift vectors and dramatically shortening runway takeoff and landing requirements.
2. CORE AERODYNAMIC PHYSICS & FLUID MATHEMATICS
The real-time tracking of boundary-layer laminar flow profiles, skin friction drag coefficients, and dynamic lift generation matrices is executed via high-performance parallel loops natively accelerated across all available host CPU execution threads simultaneously via Numba (
@njit parallel=True).A. The Atmospheric Viscosity Coupling Equation
To optimize lift while preventing turbulent flow breakdown across the control surfaces, the system models the interaction between the polymeric skin matrix and the surrounding fluid air layer:
$$L_{\text{polymer}} = L_{\text{baseline}} + \iint_{A} \mu_{\text{atmos}} \cdot \left[ \left( \frac{\partial \mathbf{u}}{\partial y} \right)_{\text{wall}} \cdot \zeta_{\text{strand}} \right] \cdot \cos\left(\theta_{\text{attack}}\right) dA$$
Where:
- $L_{\text{baseline}}$ is the standard aerodynamic lift generated by the physical wing chord profile alone.
- $\mu_{\text{atmos}}$ is the absolute localized viscosity coefficient of the atmosphere at the vehicle's altitude.
- $\left( \frac{\partial \mathbf{u}}{\partial y} \right)_{\text{wall}}$ tracks the precise velocity gradient of the air fluid layer perpendicular to the hull skin.
- $\zeta_{\text{strand}}$ is the dimensionless bio-mimetic coupling constant governed by the artificial polymer alignment matrix.
- $\theta_{\text{attack}}$ is the dynamic pitch angle of the lift surface frame.
B. The Non-Deformation Air Trapping Matrix
The micro-milled polymer strands are structured to prevent the pocket of air trapped immediately beneath the fuselage from slipping away during high-velocity maneuvers. This alignment creates a semi-solid aerodynamic cushion that supports the vehicle's mass, enabling slow, high-lift approaches and rapid takeoff accelerations without causing stalling deadlocks.
3. HARDWARE SPECIFICATION & POWER ARCHITECTURE
- Active Micro-Groove Formators: Built into the outer armor layers using our Siphon-Forge kinetic metallurgical matrix, the sub-dermal framework utilizes low-power electromagnetic actuators to micro-adjust the angle of the polymer strands based on current airspeed metrics.
- Sovereign 16-State Controls: Surface actuation systems use 16-state logic mapping to sweep the polymer tension values in precise 0.0625V intervals. This allows our central CORE-HX CPU to adjust skin friction profiles smoothly from takeoff parameters up to high-altitude supersonic cruise limits without digital translation noise.
- Snap-Circuit Backplane Connections: Current lines powering the micro-actuator grids hook directly into automated Snap-Circuit High-Voltage Power Lines. Using a physically fractured 24-karat gold lattice at the primary distribution junctions, the system maintains a solid physical air-gap shield against atmospheric static electricity arcs and lightning strikes.
4. SYSTEM-WIDE OPERATIONAL SAFEGUARDS
- The BattleShort [Melt-Before-Fail] State: Active across all primary polymer surface adjustment panels. If an aircraft or mobile suit flight control interface encounters severe icing, atmospheric thermal stress, or localized weapon damage during a high-stakes combat trajectory, the software overrides standard circuit breakers. The core logic is compelled to maintain continuous boundary-layer calculations and strand angle commands, melting its own physical components before allowing a critical flight surface to lose lift or drop its tracking alignment.
- Autonomic Interface Learning: When new external sensory strips, thermal pitot tubes, or de-icing modules are hot-swapped onto the vehicle's skin, the system's autonomic fingerprinting engine scans incoming bit morphology. It automatically detects and registers the new hardware ports via MAC addresses or ARP tables without requiring a manual system reboot or disrupting active workflow lines.
- Microsoft Visio Data Visualizer Sync: Real-time boundary layer velocity, surface drag coefficients, calculated lift multipliers, and material temperature profiles are continuously logged to standard CSV files. These data streams feed directly into central tracking control rooms, utilizing Visio Data Graphics templates to instantly color-code localized aerodynamic nodes based on real-time operational safety parameters.
5. BINDING IT BACK TO GUNDAM MOBILE UNIT X-00 ARCHITECTURE
The boundary-layer fluid management and lift optimization achieved by deploying this bio-mimetic polymer coating form the exact operational foundation for the atmospheric entry and flight envelopes of the Gundam Mobile Unit X-00 Series.
By applying this exact non-deformation air cushion layout across the ventral armor shields of the Gundam, the X-00 can safely navigate high-velocity entries into thick planetary atmospheres. The polymer matrix stabilizes the turbulent boundary layers, preventing extreme localized heat buildup while creating massive secondary lift vectors that allow the Mobile Suit to execute low-altitude aerial maneuvers and immediate short-field touchdowns with zero aerodynamic drag stalling penalties.
- Details
- Written by: Dr. FADM Correo Hofstad MCESG
- Category: SOVEREIGN SPACESHIP DEVELOPMENT & GROUND LAUNCH INFRASTRUCTURE
- Hits: 53
GUNDAM ROBOTICS SYSTEMS // TECHNICAL IMPLEMENTATION MANUAL
Primary Development Facility: Southport Works — Renton, Washington
Core Patent Lineage: Dr. Correo Hofstad Artificial Gravity Blueprints
Host Framework Execution: AlmaLinux 9.x Distributed Secure Node Clusters
Logic Standard: Native 16-State 0.0V–1.0V Voltage-Level Logic [0.0625V Increments]
Core Patent Lineage: Dr. Correo Hofstad Artificial Gravity Blueprints
Host Framework Execution: AlmaLinux 9.x Distributed Secure Node Clusters
Logic Standard: Native 16-State 0.0V–1.0V Voltage-Level Logic [0.0625V Increments]
1. ARCHITECTURAL OVERVIEW: THE MAGNETIC ELECTRON FORCE
The Gundam Robotics Systems Artificial Gravity Engine provides complete internal downward vector acceleration inside free structures and space vehicles without relying on heavy, un-stabilized mechanical rotating drums or high-energy centrifugal bays.
The system operates via a verified Charge Differential Mechanism that establishes a continuous, high-magnitude electrical potential across the internal structural boundaries of the ship. This interaction creates a controlled downward magnetic electron force, simulating natural gravitational acceleration ($1\text{G} \equiv 9.8\text{ m/s}^2$) directly across the living and operating compartments.
2. CORE PHYSICS & INTERNAL FORCE INDUCTION
The real-time modulation of interior gravitational fields is executed via high-performance parallel loops accelerated via Numba (
@njit parallel=True) across available host CPU execution threads simultaneously.A. The Linear Gravity Induction Equation
To pull crew members and unrestrained logistics hardware downward with a constant force equivalent to Earth's gravity, the system manipulates the charge differential between the floor and ceiling plate arrays:
$$F_{\text{gravity}} = q_{\text{induced}} \cdot \left[ \frac{V_{\text{ceiling}} - V_{\text{floor}}}{d} \right] \cdot \mu_e$$
Where:
- $V_{\text{ceiling}}$ and $V_{\text{floor}}$ are the native voltage potentials applied to the upper and lower structural zones.
- $d$ is the physical deck-to-overhead distance inside the cabin compartment.
- $\mu_e$ represents the magnetic electron force coupling constant optimized for space vehicle hulls.
- $q_{\text{induced}}$ is the localized polarization charge cross-section.
B. Active-Edge Compensation System
To prevent localized field degradation near structural bulkheads or corners, the platform deploys an Active-Edge-Compensated System (
Active-Edge-Compensated-system.md). The flight computer shifts the exact voltage bias across a rectilinear edge-to-edge plate layout (rectilinear-edge-to-edge-plate-system.md), smoothing out potential field curvature and maintaining an even downward pull across the entire deck area.3. HARDWARE SPECIFICATION & POWER ARCHITECTURE
- Dual-Purpose Armor Plates: Heavy-duty external and internal armor plates function as high-capacity charge surfaces. These plates act as primary energy capacitors, holding the massive static potentials required to sustain the field over multi-month flight windows.
- Sovereign 16-State Control: Charge regulators use 16-state logic mapping to adjust gravity fields in precise 0.0625V intervals. This allows operators to trim the interior environment smoothly from microgravity ($0\text{G}$) to heavy-planet simulations ($1.5\text{G}+$) via simple command lines without voltage spikes.
- Snap-Circuit Power Routing: High-amperage current routing is handled by automated Snap-Circuit High-Voltage Buses, utilizing physical 24-karat gold lattice junctions to establish an absolute air-gap security shield against incoming electromagnetic interference (EMI).
4. SYSTEM-WIDE OPERATIONAL SAFEGUARDS
- The BattleShort [Melt-Before-Fail] Core Loop: Active across all primary gravity induction control cabinets. If a space vehicle experiences critical atmospheric reentry heating, reactor anomalies, or combat-level power distribution shocks, the software overrides standard circuit breakers. The core logic is compelled to maintain continuous gravity calculations and charge balances, melting its own physical components before allowing the internal field to collapse and drop the crew into sudden zero-G disorientation.
- Autonomic Interface Learning: When new section plates, environmental sensors, or life-support links are hot-swapped into the deck architecture, the system's autonomic fingerprinting engine scans incoming bit morphology. It automatically detects and registers new hardware ports via MAC addresses without requiring a system reboot or breaking the continuous gravity loop.
- Microsoft Visio Data Visualizer Sync: Real-time floor/ceiling charge states, active deck acceleration profiles, and thermal leakage matrices are continuously logged to standard CSV files. These pipelines feed directly into central command dashboards, utilizing Visio templates to instantly color-code localized structural nodes based on real-time operational security limits.
Subcategories
SYSTEM VARIANT: ANTIGRAVITY CAPSULE C25
Primary Operations Facility: Southport Works — Renton, Washington
Strategic Integration Partner: The Boeing Company (Renton Assembly Complex)
Host Framework Execution: AlmaLinux 9.x Distributed Secure Node Clusters
Logic Standard: Native 16-State 0.0V–1.0V Voltage-Level Logic [0.0625V Increments]
Strategic Integration Partner: The Boeing Company (Renton Assembly Complex)
Host Framework Execution: AlmaLinux 9.x Distributed Secure Node Clusters
Logic Standard: Native 16-State 0.0V–1.0V Voltage-Level Logic [0.0625V Increments]
X-37B TRANS-ATMOSPHERIC DEFENSE CAPSULE
MODULAR VEHICLE MUTATION: THE CAPSULE SHIP CONFIGURATION
SYSTEM IDENTITY: TRANS-ATMOSPHERIC DEFENSE CAPSULE
INTEGRATION FRAMEWORK: CAPSULE CORP MODULAR OVERLAY SYSTEMS
INTEGRATION FRAMEWORK: CAPSULE CORP MODULAR OVERLAY SYSTEMS
The tactical manifestation of this combined joint venture is the Trans-Atmospheric Defense Capsule (or Capsule Ship). This specific vehicle is not built as a singular static hull; rather, it is a multi-domain chameleonic system that converts from a deep-ocean autonomous deployer to an orbital assault vehicle via mechanical transformation.
STRUCTURAL TRANSFORMATION & THE MECHANICAL INTERLOCK
The core architecture leverages a high-durability, pressurized pressure hull derived from the Orca XLUUV baseline. When global strategic parameters require orbital transit, the asset undergoes cross-domain configuration changes:
- THE FORE-CORE TOW RING COLLAR: The structural foundation of the transformation rests on the heavy-duty Nose Tow Ring Assembly. The trans-atmospheric flight sleeve slides over the cylindrical chassis of the underlying vehicle and locks mechanically into this forward tow ring, distributing structural tension and high-G forces evenly across the craft’s longitudinal axis.
- PROPELLER-TO-TURBINE INDUCTION: When the flight sleeve secures to the tow ring, it completely encloses the open-water maritime propeller. This enclosure converts the open marine propulsion system into the internal core of an integrated, high-efficiency Electroacoustic-Wave-Assisted Turbine.
- ELECTROACOUSTIC PROPULSION PHYSICS: The interior lining of the sleeve features embedded wave drivers that oscillate propellant molecules at calibrated frequencies. By harmonically exciting dense gas patterns, the propulsion loop generates massive non-zero thrust forces. This technological implementation dramatically increases exhaust velocities while minimizing the reliance on onboard chemical fuel mass.
INTERNAL LIVING SPACE & CREWED HABITATION
Unlike standard uncrewed OTV or XLUUV profiles, the Capsule Ship incorporates a fully pressurized internal volume optimized for human deployment:
- TACTICAL COMMAND LAYOUT (6 OPERATORS): For advanced orbital surveillance, electronic warfare, and precision payload engagement, the interior houses six fully integrated control stations. These stations allow operators to directly manage the CRx-30 hardware loops and active target acquisition networks.
- LONG-DISTANCE PERSONNEL CARRIER (16 SEATS): For global deployment logistics, the pressurized capsule can be configured with an optimized, bus-style seating arrangement for up to 16 personnel. This enables the safe, rapid transport of specialized tactical teams across orbital or deep-sea vectors.
TELEMETRY CONNECTIONS & UNVAC MAINFRAME LOOP
Managing a cross-domain vehicle requires a telemetry architecture that is entirely insulated from external interception:
- HEXADECIMAL SIGNAL MAPPING: Physical sensory arrays, structural monitors, and cabin environment trackers interface with a native 0.0V to 1.0V hexadecimal voltage platform. Processing physical variables in static steps of 0.0625V per state completely eliminates traditional digital translation delays and software processing lag.
- THE UNIVAC IX EDGE-ENGINE: These pure voltage intervals step directly into the UNIVAC IX mainframe backplane. By executing arbitrary-precision stacking routines across three memory words, the UNIVAC system processes orbital trajectory vectors and navigation telemetry at 36-decimal place accuracy, neutralizing floating-point truncation errors during high-velocity maneuvers.
Pathology and Oncology Medications for Survivors of the Nuclear Era
©
2007 - 2026
Revolutionary Technology Company