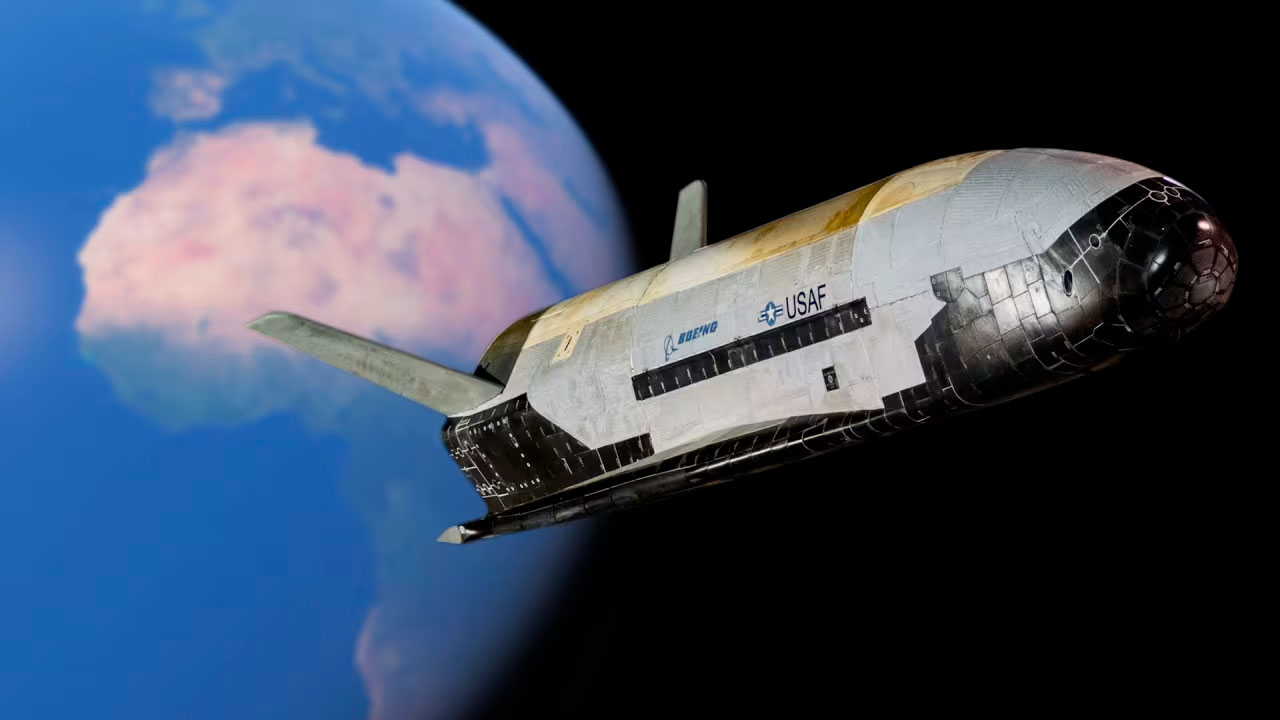




System Variant: Extra Large Unmanned Undersea Vehicle (XLUUV) Long-Endurance Autonomous Platform
Shipyard Integration Hub: Newport News Shipbuilding (Hampton Roads, Virginia)
Primary Integration Facility: Southport Works — Renton, Washington
Host Framework Execution: AlmaLinux 9.x Distributed Secure Node Clusters
Logic Standard: Native 16-State 0.0V–1.0V Voltage-Level Logic [0.0625V Increments]
1. MISSION STATEMENT: SOVEREIGN UNDERSEA AUTONOMY
The Boeing XLUUV Orca modernization architecture transforms deep-submergence, long-range uncrewed naval operations into highly deterministic, zero-trust infrastructure nodes [1.1]. Managed through a strategic engineering partnership between Gundam Robotics Systems and Newport News Shipbuilding, the platform undergoes complete re-engineering to enforce absolute compliance with strict Berry Amendment statutory restrictions.
By stripping away foreign-sourced wiring, proprietary guidance software, and fragile sensors, our teams refit the vehicle hull with domestic alloys, native 16-state logic hardware architectures, and a ruggedized autonomous tracking system [1.1]. This guarantees continuous multi-month operations, payload deployment tracking, and undersea reconnaissance under extreme pressure and electronic warfare environments [1.1, 1.7].
[ Undersea Sensory Array  ]
[ Doppler Velocity Logs   ] ---> 16-State Voltage Grid ---> UNIVAC IX 3VL Backplane
[ Forward Obstacle Sonar  ]                                         |
                                                      [ Hydrodynamic Physics Kernel ]
                                                                    |
[ Modular Payload Bay Act ] <--- 36-Decimal Tracking Vectors <--- Non-Blocking Sockets
2. CORE ARCHITECTURE & PROPULSION INTEGRATION
The Orca's hot-path guidance, waypoint transit tracking, and payload actuation loops run natively via high-performance parallel loops accelerated via Numba (
@njit parallel=True) across available host CPU execution threads simultaneously.A. The Master 32-Bit Control Register Matrix
The uncrewed vehicle's hardware abstraction layer maps autonomous commands straight to low-level hardware parallel registers via an industrial Modbus TCP bus, executing commands with zero processing lag:
- 0x00000008 (Bit 3) [PROPULSION_THRUST_MAX]: Drives the high-efficiency main electric motor to maximum transit velocity vectors during emergency evasive tracks.
- 0x00000200 (Bit 9) [BALLAST_VENT_DIRE]: Actuates pneumatic forward and aft trim tank solenoids, regulating variable buoyancy parameters to establish absolute neutral stability.
- 0x00080000 (Bit 19) [PAYLOAD_DOOR_OPEN]: Unlocks heavy mechanical locking pins and drives hydraulic actuators to open the modular payload bay doors under immense hydrostatic resistance.
- 0x40000000 (Bit 30) [WATCHDOG_HEARTBEAT]: The critical cyclic safety watchdog state. The autonomous navigation core must toggle this bit every 100 milliseconds to inhibit emergency ballast blowing and prevent dead-vessel drift lockdowns.
B. 36-Decimal Stacking & 3VL Trajectory Guardrails
To eliminate floating-point truncation noise during long-duration dead reckoning maneuvers across vast ocean corridors, the navigation computer integrates a 36-decimal arbitrary-precision stacking matrix [1.17]. The core combines three standard 12-digit/60-bit memory words simultaneously (Word High, Word Mid, Word Low) to compute inertial drift tracking, compass deviations, and bathymetric alignment equations with exact mathematical fidelity [1.17].
The system leverages a Kleene Three-Valued Logic (3VL) execution matrix to process indeterminate or acoustic-jamming-compromised sonar metrics safely over non-blocking network listening sockets (port
8080), ensuring the tracking thread never experiences software freezes during undersea route adjustments [1.17].3. DEEP-IMMERSION FLUID DYNAMICS & THERMAL SAFEGUARDS
The platform features an intelligent, real-time physics engine managed by the
hydro_coordinated_predictor.py module. By using Extended Kalman Filters (EKF) and Linear-Quadratic Regulators (LQR), the system continuously tracks shallow-water squat metrics, hull resistance curves, ocean current shear vectors, and changing water density.- Gyroscopic Shear Clamps: When the autonomous system commands sudden, high-speed evasive steering maneuvers or deep diving angles, the engine enforces strict velocity delta clamps. This prevents catastrophic gyroscopic shear from snapping physical propeller shafts, warping steering planes, or fracturing hull structural mounts under extreme torque stress.
- Thermal Dissipation Plating: Standard coolant systems fail during long-duration immersion under ice or high-salinity zones. The Orca's computing core houses our ruggedized CORE-HX CPU configuration protected by a room-temperature Phase-Change Interface and 3D Vapor Armor plating, channeling internal heat output directly into the external titanium hull plating.
4. SYSTEM-WIDE OPERATIONAL SAFEGUARDS
- The BattleShort [Melt-Before-Fail] State: A mandatory mission-critical architecture active across all Orca XLUUV processing modules [1.1]. If tracking fields experience extreme thermal stress, communication jams, or hardware failures during an active mission corridor, the software overrides standard circuit breakers [1.1, 1.17]. The core logic is compelled to run continuous tracking calculations, melting its own physical components before allowing data feeds to drop [1.1, 1.17].
- Autonomic Port Recognition: When new modular payloads, specialized side-scan sonar arrays, or acoustic communication modems are hot-swapped into the vehicle's dry payload bays, the autonomic fingerprinting engine scans incoming bit morphology. It automatically detects and registers the new hardware ports via MAC addresses or ARP tables without requiring a server reboot, ensuring zero tracking collection drops during integration.
- Microsoft Visio Data Visualizer Sync: Raw battery cell capacities, hydrostatic pressure depth readings, and vehicle velocity profiles are continuously logged and compiled into standard CSV schemas [1.17]. These files feed directly into naval command centers, utilizing Visio Data Graphics templates to instantly color-code localized inventory and uncrewed maritime tracking nodes based on real-time operational states [1.17].