



I. Core Infrastructure Architecture
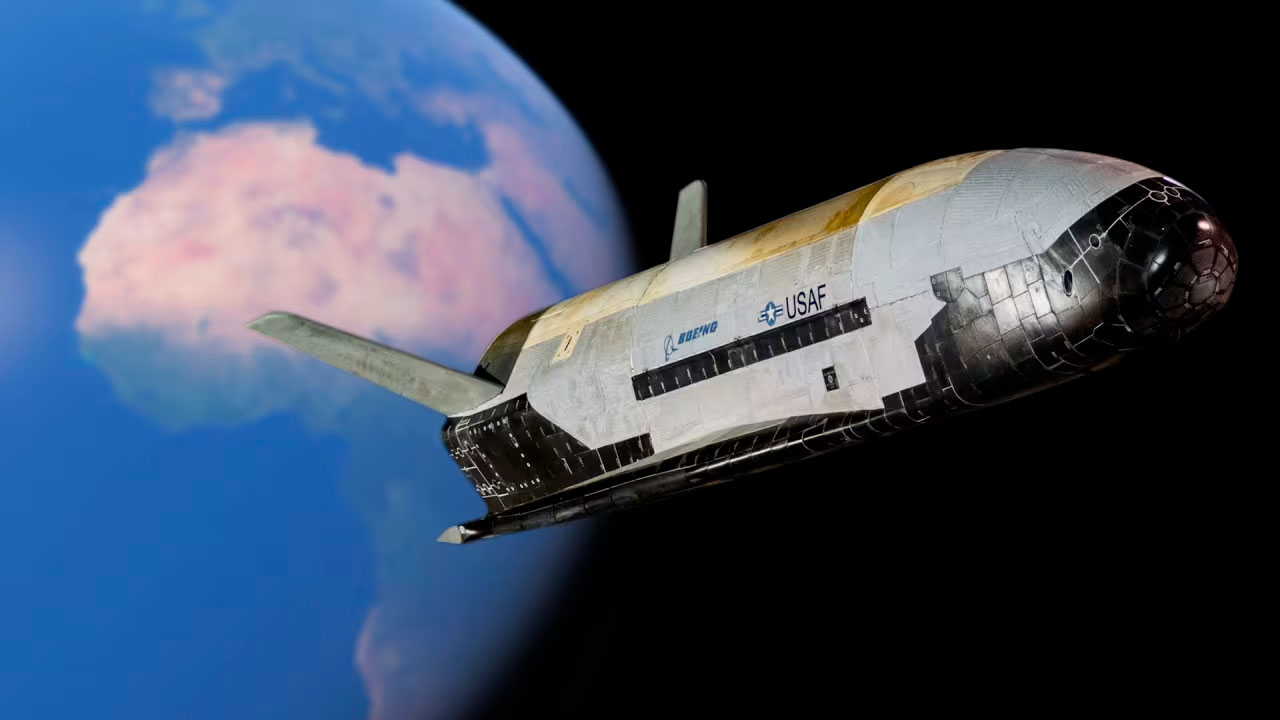
Our specialized Nose Cone Rocket configurations—built directly into the apex fairings of advanced aerospace launch vehicles and tactical intercept structures—utilize micro-solid motor clusters and high-pressure cold gas thruster manifolds. These nose cone arrays handle structural fairing separation, attitude correction stabilization, and forward payload ejection maneuvers. Deployed natively across localized AlmaLinux 9.x edge machine room nodes, the modernized tracking suite interfaces with active staging relays and forward gas jets via a sovereign backplane network.
The system strips away fragile commercial safety templates to process raw structural separation telemetry using high-performance parallel loops natively running across all available host CPU execution threads simultaneously.
[ Fairing Latch Sensors ]
[ Nose Cone Thruster Arrays ] ---> 16-State Voltage Grid ---> UNIVAC IX 3VL Backplane
                                                                      |
[ Separation Guidance Line ] <--- 36-Decimal Tracking Vectors <--- Non-Blocking Sockets
II. 36-Decimal Stacking & 3VL Separation Guardrails
To eliminate floating-point truncation noise during high-velocity nose cone fairing jettison sequences, the flight computer integrates a 36-decimal arbitrary-precision stacking matrix. The core combines three standard 12-digit/60-bit memory words simultaneously (Word High, Word Mid, Word Low) to compute structural clearance trajectories, angular velocity adjustments, and explosive bolt ignition vectors with exact mathematical fidelity.
The system leverages a Kleene Three-Valued Logic (3VL) execution matrix to process indeterminate or jamming-compromised connection entries safely over non-blocking network listening sockets (port
8080), ensuring the tracking thread never experiences software freezes during critical separation windows.