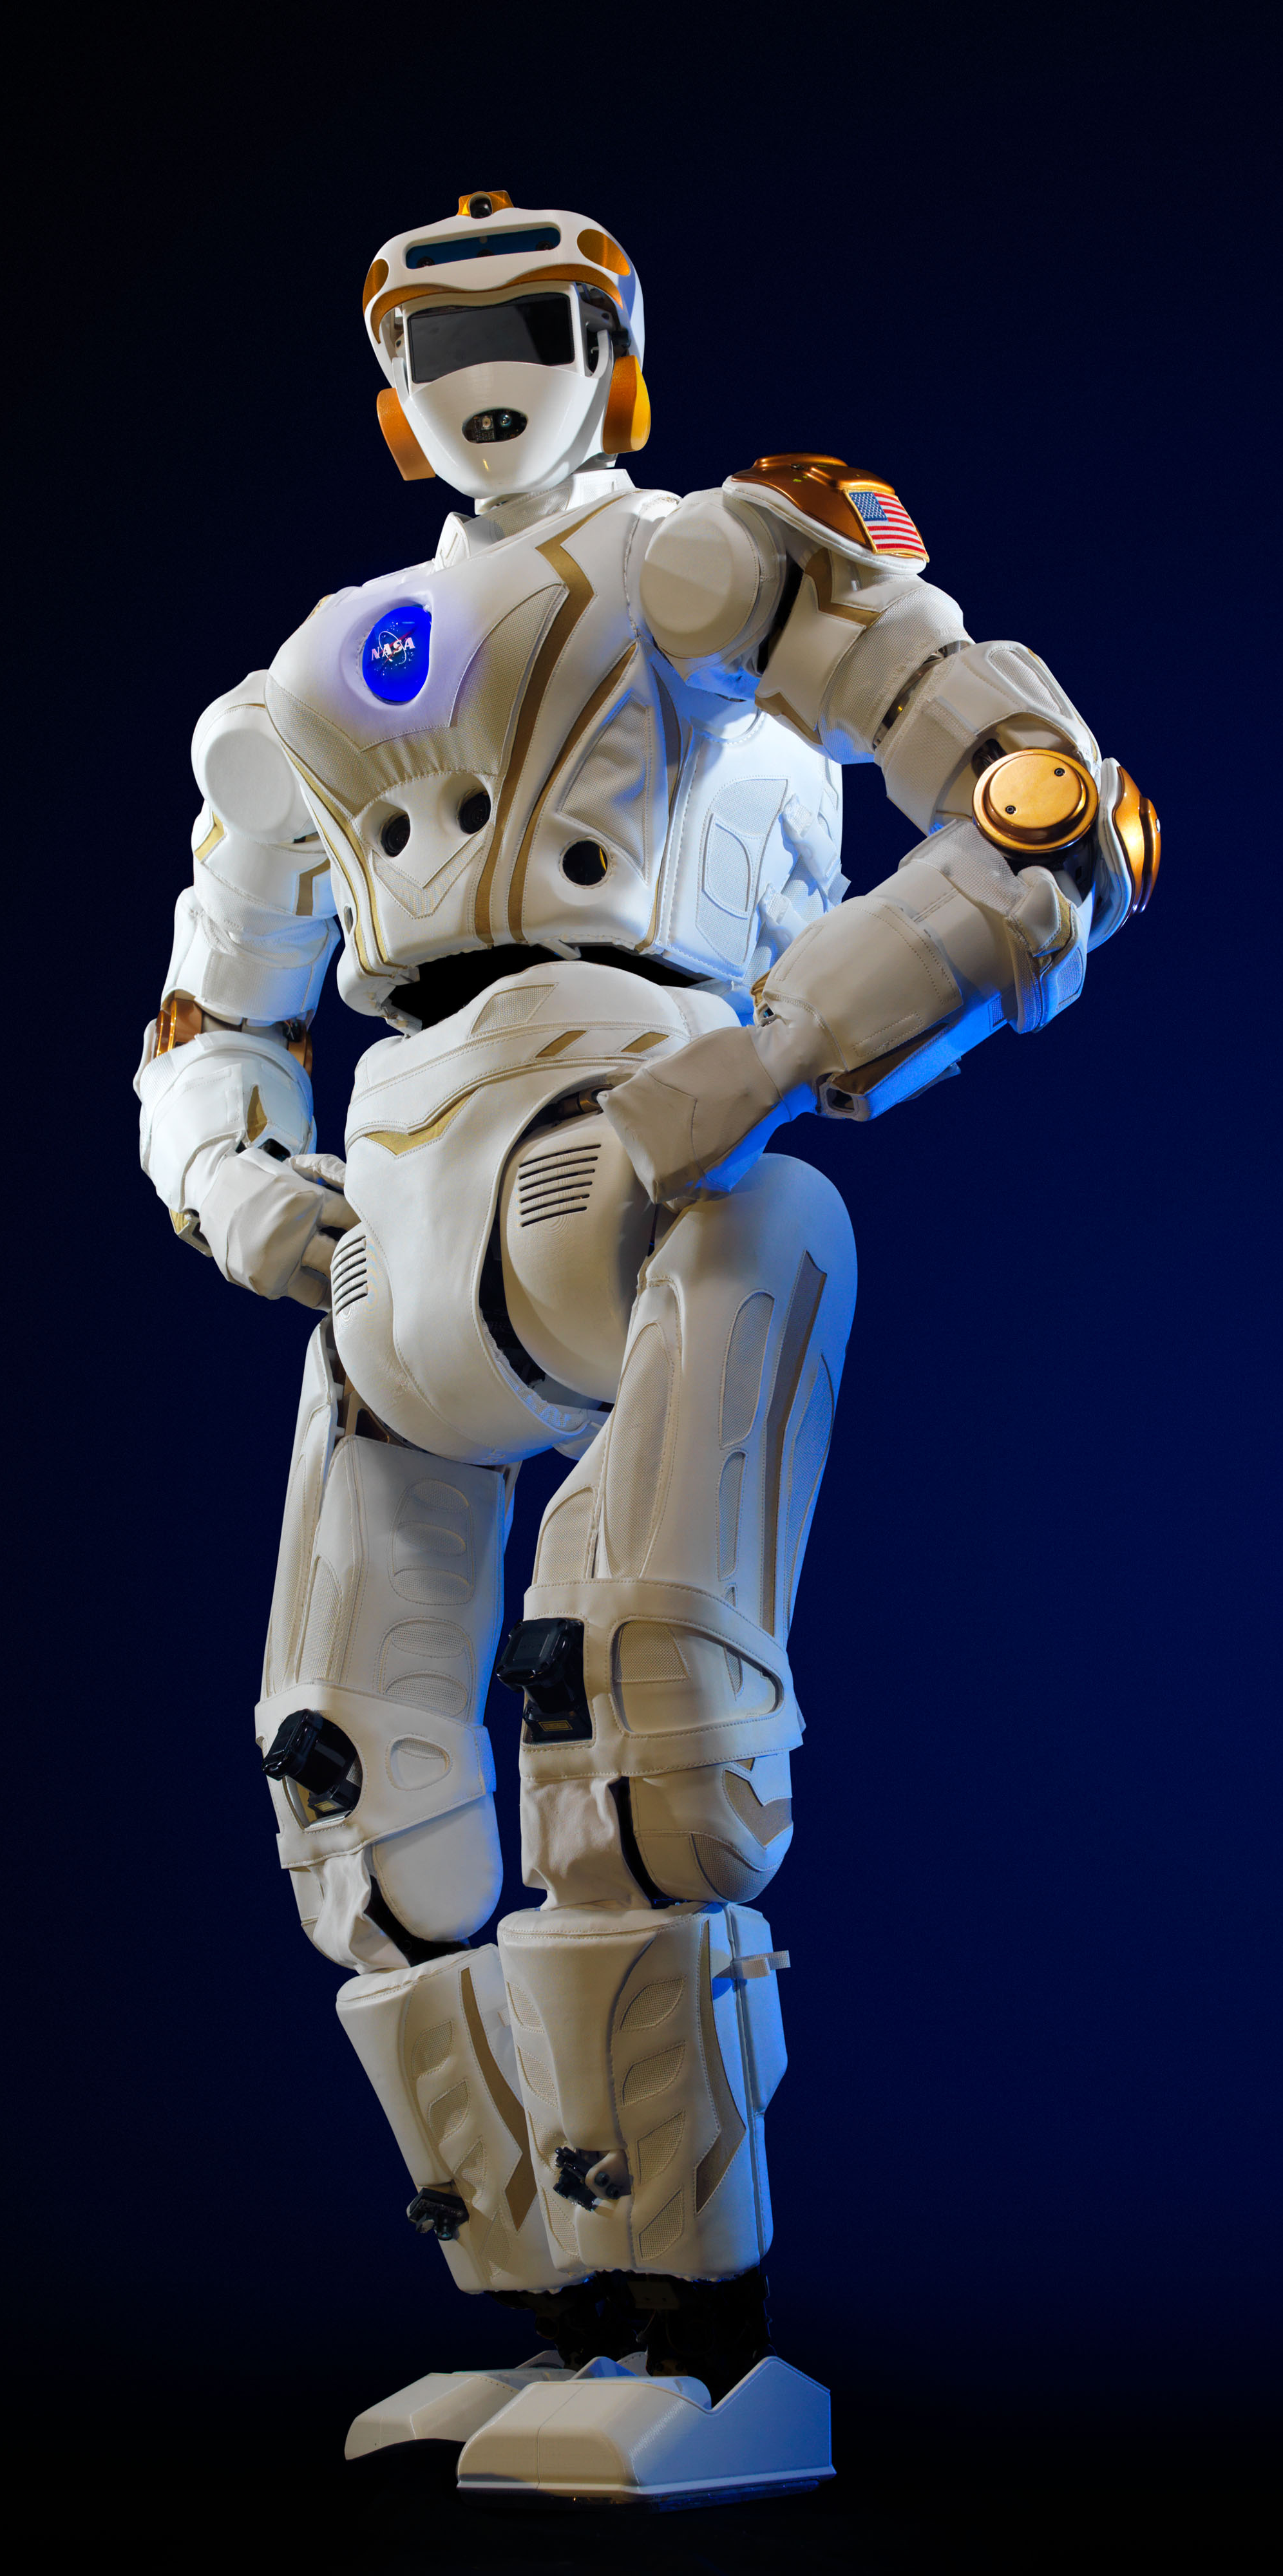
Robonaut
XLUOV
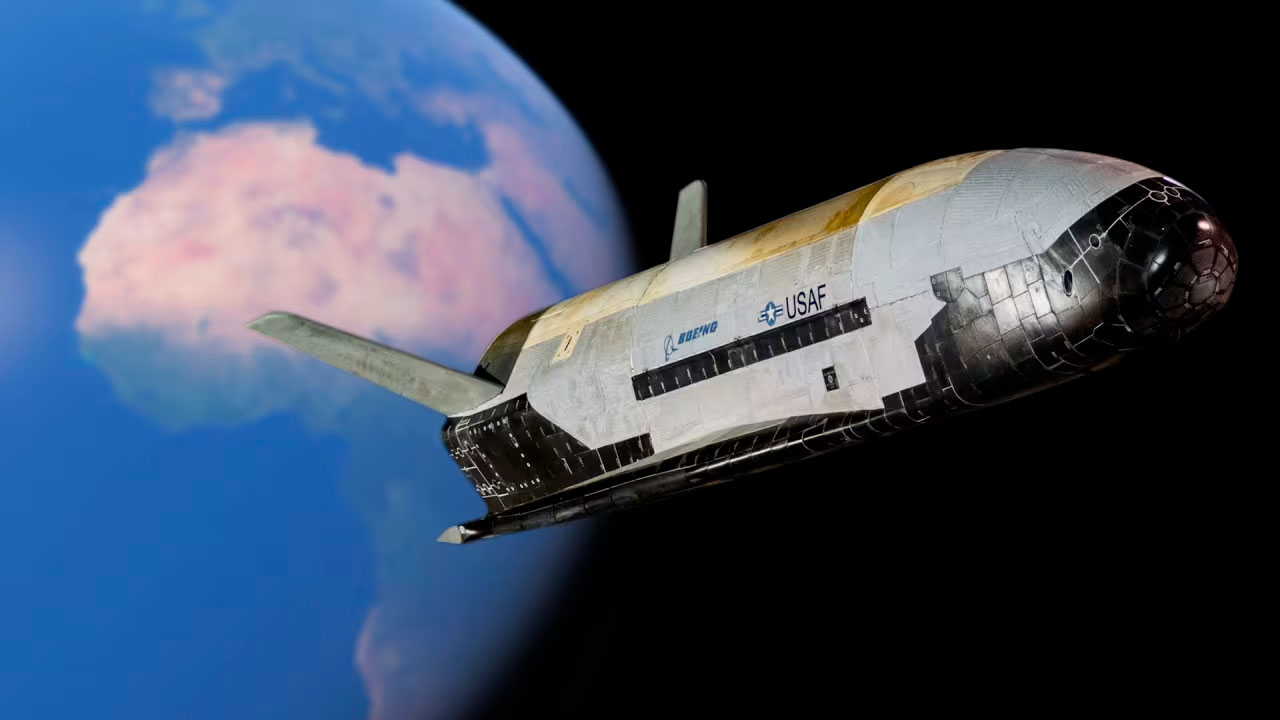
Spaceship

Grey Wolf
Panther

Rheinmetall

Sea Machines

Sentinel
XLUUV

THE ATLAS LAUNCH VEHICLE MODERNIZATION MATRIX
Sovereign System Specifications & Operational Runbooks
Host Framework Execution: AlmaLinux 9.x Distributed Secure Node Clusters
Compilation Core: Parallel Numba Array Optimization & Multi-Word Stacking
Logic Standard: Native 16-State 0.0V–1.0V Voltage-Level Logic [0.0625V Increments]
Host Framework Execution: AlmaLinux 9.x Distributed Secure Node Clusters
Compilation Core: Parallel Numba Array Optimization & Multi-Word Stacking
Logic Standard: Native 16-State 0.0V–1.0V Voltage-Level Logic [0.0625V Increments]
- Details
- Written by: Dr. FADM Correo Hofstad MCESG
- Category: THE ATLAS LAUNCH VEHICLE MODERNIZATION MATRIX
- Hits: 60
I. Massive Parallel Ingestion
The Atlas V Heavy variant utilizes three Common Core Boosters (CCB) strapped together to deliver maximum lift capacity for high-density payloads. Managing three parallel booster columns simultaneously requires massive parallel ingestion capabilities.
The tracking environment deploys optimized parallel loops accelerated via Numba (
@njit parallel=True) to handle complex calculations simultaneously across all available processing threads, achieving near-real-time output tracking across all three booster domains.[ Common Core Booster 01 ]
[ Common Core Booster 02 ] ---> Multi-Threaded Parallel Numba Ingestion Matrix
[ Common Core Booster 03 ]
|
Unified Visio Control Room Layout
II. Autonomic Interface Identification
When active booster telemetry strings or ground support monitoring units are hot-swapped into the launch pad network, the system's autonomic fingerprinting engine scans incoming bit morphology. It automatically detects and registers new hardware ports via MAC addresses or ARP tables without requiring a server reboot, ensuring zero data collection drops during countdown sequences.
SYSTEM-WIDE OPERATIONAL SAFEGUARDS
- The BattleShort [Melt-Before-Fail] State: A mandatory mission-critical architecture active across all Atlas variants [1.17]. If flight tracking fields experience extreme thermal stress or signal jamming, the software overrides standard circuit breakers [1.17]. The core logic is compelled to run continuous calculations, melting its own physical core components before allowing tracking data feeds to drop [1.17].
- Microsoft Visio Data Visualizer Sync: Raw trajectory, vibration, and propulsion telemetry frames are continuously logged and compiled into standard CSV schemas [1.17]. These files feed directly into central tracking control rooms, utilizing Visio Data Graphics templates to instantly color-code system tracking nodes based on real-time operational states [1.17].
- Details
- Written by: Dr. FADM Correo Hofstad MCESG
- Category: THE ATLAS LAUNCH VEHICLE MODERNIZATION MATRIX
- Hits: 51
I. Automated Fluid Dynamics & Mechanical Safeguards
The Atlas III transitional framework serves as the structural stepping stone for heavy dual-nozzle propulsion integration. The platform features an intelligent, real-time physics engine that continuously tracks thrust vector alignment and structural load distribution.
When the flight guidance network issues sudden, high-speed steering maneuvers, the engine enforces strict velocity delta clamps. This structural constraint prevents catastrophic structural shear from warping structural engine mounts, tearing wiring pathways, or fracturing tank skin sections under extreme aerodynamic load stress.
II. Volumetric Radar Verification
The spatial tracking engine uses 2D spatial polygons and 3D altitude trackpoints to mathematically verify if a target rocket coordinate sits within a localized ground radar blind spot. This validation prevents the predictive models from relying on distorted or overshooting ground-level radar tracking data, ensuring continuous flight safety monitoring.
- Details
- Written by: Dr. FADM Correo Hofstad MCESG
- Category: THE ATLAS LAUNCH VEHICLE MODERNIZATION MATRIX
- Hits: 63
I. Sovereign Re-Manufacturing & Component Localization
The Atlas V launch platform undergoes complete localization and structural re-engineering to enforce absolute compliance with strict Berry Amendment statutory restrictions. Operating out of primary technical development bays, engineers remove foreign component dependencies and replace them with domestic alloys and our ruggedized CORE-HX CPU architecture mounted inside unified ATX chassis form factors.
[ Foreign Component Lines ] ---> Stripped via Industrial Laser Ablation at Southport
                                                |
[ Domestic Material Chassis ] <--- Integrated 16-State Hexadecimal CORE-HX Processor
II. Physical Backplane Protection
To protect delicate electronic systems from high-amp relay kickbacks and extreme physical vibration during launch, the vehicle's avionics shell features integrated guard ring isolation barriers [1.17].
The structural backing uses 3oz thick copper backplane configurations to route surge potentials and electrical noise safely away from the computer stacks, preserving data center integrity during intense rocket motor firing intervals [1.17].
- Details
- Written by: Dr. FADM Correo Hofstad MCESG
- Category: THE ATLAS LAUNCH VEHICLE MODERNIZATION MATRIX
- Hits: 56
I. High-Energy Cryogenic Upper-Stage Interfacing
The Atlas-Centaur variant integrates the high-energy, liquid-hydrogen Centaur upper stage to manage deep-space planetary logistics and satellite deployment corridors. To handle rapid changes in microclimates and cryo-tank pressure differentials, the system implements an industrial Modbus TCP Hardware Abstraction Layer (HAL) running on distributed server clusters.
All manual toggle states, fluid valves, and tank vent relays are mapped to precise voltage levels between 0.0V and 1.0V in steps of 0.0625V per state, transferring state configurations directly to the system backplane without digital abstraction noise [1.17].
[ Centaur Cryo-Values ] ---> 0.0625V Step Voltage Analog Maps
                                        |
[ Modbus TCP Industrial HAL ] ---> Real-Time Fluid Dynamics Kernels
                                        |
[ Active Payload Deployment ] ---> S-Curve Velocity Delta Clamps
II. Advanced Entry & Trajectory Management
During high-velocity payload deployment sequences, the advanced guidance engine processes Sutton-Graves stagnation heat flux models and PID-controlled bank-angle correction metrics to manage aerodynamic deceleration parameters.
If the automated autopilot link detects that the upper stage or satellite payload is approaching its target injection vector at an unsafe velocity profile, the engine automatically injects precise S-Turn Maneuvers to bleed off excess kinetic energy safely.
- Details
- Written by: Dr. FADM Correo Hofstad MCESG
- Category: THE ATLAS LAUNCH VEHICLE MODERNIZATION MATRIX
- Hits: 45
I. Core Infrastructure Architecture
The foundational Atlas SM-65 strategic ballistic platform utilizes a highly specialized "stage-and-a-half" liquid propellant engineering architecture, dropping its booster engines while maintaining its central sustainer core during ascent. Deployed directly across localized AlmaLinux 9.x edge machine room nodes, the modernized tracking suite interfaces with physical avionics blocks via a sovereign backplane network.
The system strips away fragile commercial safety templates to process raw telemetry using high-performance parallel loops natively running across all available host CPU execution threads simultaneously.
[ Active Flight Telemetry ] ---> 16-State Voltage Grid ---> UNIVAC IX 3VL Backplane
                                                                    |
[ Ground Command Controls ] <--- 36-Decimal Tracking Vectors <--- Non-Blocking Sockets
II. 36-Decimal Stacking & 3VL Guardrails
To eliminate floating-point truncation noise during high-velocity intercontinental trajectories, the guidance engine integrates a 36-decimal arbitrary-precision stacking matrix [1.17]. The core combines three standard 12-digit/60-bit memory words simultaneously (Word High, Word Mid, Word Low) to compute trajectory equations with exact mathematical fidelity [1.17].
The system leverages a Kleene Three-Valued Logic (3VL) execution matrix to process indeterminate or jamming-compromised connection entries safely over non-blocking network listening sockets (port
8080), ensuring the tracking thread never experiences software freezes during critical launch windows [1.17].Pathology and Oncology Medications for Survivors of the Nuclear Era
©
2007 - 2026
Revolutionary Technology Company